Start here
A few places to begin, from the aircraft’s story to the people who fly it.
Meet the aircraft
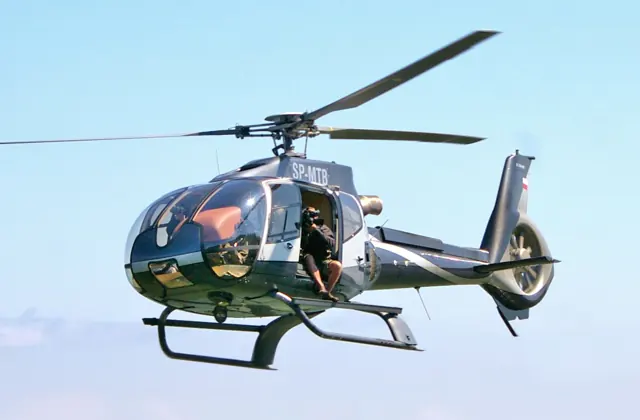
The Kaman K-MAX is a helicopter designed specifically for repetitive external-load work.
Kaman K-MAX
store.x-plane.org · Read more ↗Meet Kaman K-MAX
The Kaman K-MAX is a helicopter designed specifically for repetitive external-load work.
Kaman K-MAX
Kaman → · Explore the family →
Kaman K-MAX
store.x-plane.org · Kaman K-MAX — aircraft background ↗Aircraft type designators
No type designator selected for this reference.
History & design
A helicopter built around the load
Kaman’s company history dates the K-MAX introduction to 1992. It was designed around repeated external lifting, with logging, construction, firefighting and other aerial-work tasks forming its purpose rather than adapting a passenger cabin to carry cargo.
Kaman · Company history ↗Kaman K-MAX commercial lifting helicopter
A narrow fuselage for vertical reference
The manufacturer emphasizes the pilot’s view down toward the load and a heavy-duty trolley system for placement. The absence of a tail rotor and the emphasis on external cargo distinguish its layout from conventional utility helicopters.
Kaman · K-MAX commercial brochure, revision 2.22.2022 ↗Kaman K-MAX commercial lifting helicopter
Systems & details
Lift capability changes with conditions
The 6,000 lb cargo-hook rating is not a promise to lift that load everywhere. The same brochure shows reduced lift capability as altitude rises at ISA plus 15°C, and separate in-ground-effect and out-of-ground-effect hover limits. The unloaded and external-load speed limits also differ.
In your simulator
Systems, equipment and documentation for each developer’s aircraft.
X-Plane 12K-1200 K-MAX
STMA · Released
K-1200 K-MAX
STMA · Released
Manuals & resources
Find your next read
Choose a topic for a short introduction and a link to the original source. Simulator references identify the developer and edition they cover.
Manufacturer, developer or authorized-product aircraft context
Kaman K-MAX — aircraft backgroundKaman K-MAX
Background on the Kaman K-MAX and its external-load role.
Aircraft-context passage, preserved text line 48; reviewed 2026-09-29
store.x-plane.org · Read the source ↗Developer documentation
K-1200 K-MAX — product listingK-1200 K-MAX · X-Plane 12
Individual product listing and edition passage reviewed 2026-09-29
store.x-plane.org · Read the source ↗Read the original documentation from the people who created it. Manuals open on their publisher’s website.
Manufacturer, developer or authorized-product aircraft context
Kaman K-MAX — aircraft backgroundstore.x-plane.org · Aircraft-context passage, preserved text line 48; reviewed 2026-09-29Aircraft documentation
Company historyKaman · Manufacturer account of 1992 introduction; dated company history, not current deployment status K-MAX commercial brochure, revision 2.22.2022Kaman · Commercial lifting configuration; printed revision 2.22.2022Built-in force-feedback profiles
Read the documentary basis, editable starting settings and remaining questions for the aircraft you fly. Each explanation refers to the exact profile revision shown.
Catalogue programme-20261022-v1 · 2 profile choices
STMA Kaman K-1200 K-MAX
STMA · Free and Pro · Revision 1 · Inherited starting point
X-Plane 12
The Kaman K-MAX is a helicopter designed specifically for repetitive external-load work.
Kaman K-1200 K-MAX
Free and Pro · Revision 1 · Partial review
MSFS 2020 · MSFS 2024 · X-Plane 12
The Kaman K-MAX is a helicopter designed specifically for repetitive external-load work.
Kaman K-1200 K-MAX
The Kaman K-MAX is a helicopter designed specifically for repetitive external-load work.
Aircraft and simulator scope
- Kaman K-1200 K-MAX · MSFS 2020 · Variant starting point
- Kaman K-1200 K-MAX · MSFS 2024 · Variant starting point
- Kaman K-1200 K-MAX · X-Plane 12 · Variant starting point
Universal named airframe/configuration; intended MSFS2020/MSFS2024/XP12 starting point, not add-on or edition acceptance. · Physical facts and prior documentary review are reused from their archived dated sources; new market availability is not inferred.
The simulator model and controls
The Kaman K-MAX is a helicopter designed specifically for repetitive external-load work.
How this profile feels
The spring stays independent of airspeed. Directed aerodynamic loading is omitted.
Local force trim is off. Autopilot following is off.
Aircraft and configuration
The product documents an external-lift role and intermeshing counter-rotating synchropter rotors.
About the values
Strengths are normalized hardware-feel settings. They set the effect balance; hand force depends on the device and its limits. The IAS reference is a tuning value.
What the documentation establishes
Kaman K-1200 K-MAX: The product documents an external-lift role and intermeshing counter-rotating synchropter rotors.
Documentary review and sources
These decisions describe the documentary basis and remaining gaps for this revision. Aircraft documentation and a starting setting describe different kinds of evidence.
Aircraft and variant
ReviewedThe Kaman K-MAX is a helicopter designed specifically for repetitive external-load work.
Flight controls
InheritedThe Kaman K-MAX is a helicopter designed specifically for repetitive external-load work.
Trim
InheritedLocal force trim is off. Autopilot following is off.
Autopilot and stability
ReviewedAutopilot following is off; the configured spring and load retain the hardware feel.
Equipment
InheritedThe product documents an external-lift role and intermeshing counter-rotating synchropter rotors.
Speeds and limits
InheritedThe indicated-speed references set the profile response scale; they are separate from aircraft operating limits.
Simulator integration
ReviewedThe profile targets msfs2020, msfs2024, xplane12. Add-on-specific controls use only the supported references configured by this profile.
Force-feedback settings
InheritedThe settings define the profile’s effect balance. Device output limits affect physical hand force.
Starting settings and their rationale
These configured values are starting estimates. The explanations describe what each setting controls; physical validation appears separately below.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring strength | Starting value0.1 | What it controls and whyThis profile uses cyclic loading for Kaman K-MAX. The baseline spring is 0.1. Low-speed spring blending is off. |
| Master force gain | Starting value0.65 | What it controls and whyScales overall profile strength while preserving effect balance, subject to device and output limits. |
| Profile force gain | Starting value0 | What it controls and whyThe 0 gain omits sustained directed airspeed loading. Spring resistance remains independent. |
| Force tuning speed/reference | Starting value85 kt | What it controls and whySets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Spring response reference speed | Starting value42.5 kt | What it controls and whySets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Aileron force scale | Starting value0.7 | What it controls and whyRoll and pitch aerodynamic scales are 0.7 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled. |
| Elevator force scale | Starting value1 | What it controls and whyScales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Trim feel | Starting valueDisabled | What it controls and whyRetained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| Trim relief | Starting valueDisabled | What it controls and whyAllows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| Autopilot follow | Starting valueDisabled | What it controls and whyAutopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot neutral hold | Starting valueDisabled | What it controls and whyPermits centering hold during a supported AP state, separate from following a moving target. |
| Output force limit | Starting value0.55 | What it controls and whyCaps directed-force output. Native spring effects and device limits remain separate. |
All 44 starting settings and their rationale
The settings define the profile’s effect balance. Device output limits affect physical hand force.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring strength | Starting value0.1 | What it controls and whyThis profile uses cyclic loading for Kaman K-MAX. The baseline spring is 0.1. Low-speed spring blending is off. |
| Profile force gain | Starting value0 | What it controls and whyThe 0 gain omits sustained directed airspeed loading. Spring resistance remains independent. |
| Elevator force scale | Starting value1 | What it controls and whyScales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Aileron force scale | Starting value0.7 | What it controls and whyRoll and pitch aerodynamic scales are 0.7 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled. |
| Output force limit | Starting value0.55 | What it controls and whyCaps directed-force output. Native spring effects and device limits remain separate. |
Kaman K-1200 K-MAX: Custom cyclic/FTR relationship unqualified; local trim disabled. Estimated pitch/roll trim authorities 0/0; exact add-on sign, travel, units and build-specific neutral remain unqualified. Rudder trim never substitutes for roll trim.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Elevator Authority | Starting value0 | What it controls and whyScales supported pitch-trim relief and permitted centre movement. Zero removes pitch response. |
| Aileron Authority | Starting value0 | What it controls and whyScales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
Kaman K-1200 K-MAX: 85 KIAS is the retained estimated tuning reference. It is not published cruise TAS, VNE, a new flight limit or a measured force threshold. Source-specific operating quantities remain attached to their original configuration and conditions.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Force tuning speed/reference | Starting value85 kt | What it controls and whySets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
The rotor-RPM force contract is unqualified. Engine texture remains disabled; rotor geometry does not establish a calibrated vibration harmonic.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Gain | Starting value0 | What it controls and whyThe rotor-RPM force contract is unqualified. Engine texture remains disabled; rotor geometry does not establish a calibrated vibration harmonic. |
Exact configured values with software explanations. Force magnitudes remain editable estimates; disabled features retain inactive values.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring deadband | Starting value0.02 | What it controls and whySets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Master force gain | Starting value0.65 | What it controls and whyScales overall profile strength while preserving effect balance, subject to device and output limits. |
| QBlend Enabled | Starting valueDisabled | What it controls and whyAllows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| QSpring Minimum Factor | Starting value1 | What it controls and whySets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| QSpring Start Knots | Starting value8 kt | What it controls and whySets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring response reference speed | Starting value42.5 kt | What it controls and whySets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Airspeed spring stiffening gain | Starting value0 | What it controls and whyAdds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase. |
| Airspeed spring stiffening limit | Starting value5 | What it controls and whyLimits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Trim feel | Starting valueDisabled | What it controls and whyRetained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| Trim relief | Starting valueDisabled | What it controls and whyAllows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| Force Trim Enabled | Starting valueDisabled | What it controls and whyThe profile uses the trim behaviour configured below. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral. |
| GLoad Enabled | Starting valueEnabled | What it controls and whyAllows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| Rate Damping Enabled | Starting valueDisabled | What it controls and whyEnables rate damping with the configured coefficients and control law. |
| Autopilot follow | Starting valueDisabled | What it controls and whyAutopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot follow authority | Starting value0.05 | What it controls and whySets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot neutral hold | Starting valueDisabled | What it controls and whyPermits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot neutral hold strength | Starting value0.6 | What it controls and whySets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Enabled | Starting valueEnabled | What it controls and whyEnables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Gain | Starting value0 | What it controls and whySets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Gain | Starting value0 | What it controls and whySets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Gain | Starting value0 | What it controls and whySets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Maximum flap index | Starting value1 | What it controls and whySets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Minimum flap index | Starting value1 | What it controls and whySets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Gain | Starting value0 | What it controls and whySets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Shaker Enabled | Starting valueDisabled | What it controls and whyPermits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Stick shaker amplitude | Starting value0.5 | What it controls and whySets triggered shaker strength; inactive while the shaker feature is disabled. |
| Enabled | Starting valueEnabled | What it controls and whyEnables ground effects; each still needs its own strength and contact or motion telemetry. |
| Gain | Starting value0 | What it controls and whySets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Gain | Starting value0 | What it controls and whySets gear-bump texture during ground motion, separate from touchdown impact. |
| Gain | Starting value0.2 | What it controls and whySets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Gain | Starting value0 | What it controls and whySets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Enabled | Starting valueEnabled | What it controls and whyEnables engine cues with nonzero settings and valid running-engine telemetry. |
| Enabled | Starting valueEnabled | What it controls and whyEnables accessory cues with configured strengths and observed accessory movement. |
| Gain | Starting value0 | What it controls and whySets texture from observed flap movement; a command without movement does not establish the cue. |
| Gain | Starting value0 | What it controls and whySets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
Limits and open questions
- Kaman K-1200 K-MAX is a universal starting point; exact add-on matching, edition operation and physical hand-force calibration remain unqualified.
- Autopilot movement and unknown custom trim, failure or force-input signals are disabled. Confirm the selected equipment fit and trim direction for the implementation in use.
- Force magnitudes and speed tuning are editable inherited estimates. Owner physical and installed-aircraft acceptance remain pending.
Physical validation
No physical force validation is recorded in this public catalogue for this revision. Documentary review and software checks do not establish how a particular device feels.
Discuss this aircraft (0)
Questions, observations and useful sources from the community.
No published discussions yet. Bring a question or share a useful source.
Open aircraft discussions →Content expanded · What’s new
Something missing or a source that needs attention?
Suggest a correction ↗