Start here
A few places to begin, from the aircraft’s story to the people who fly it.
Meet the aircraft
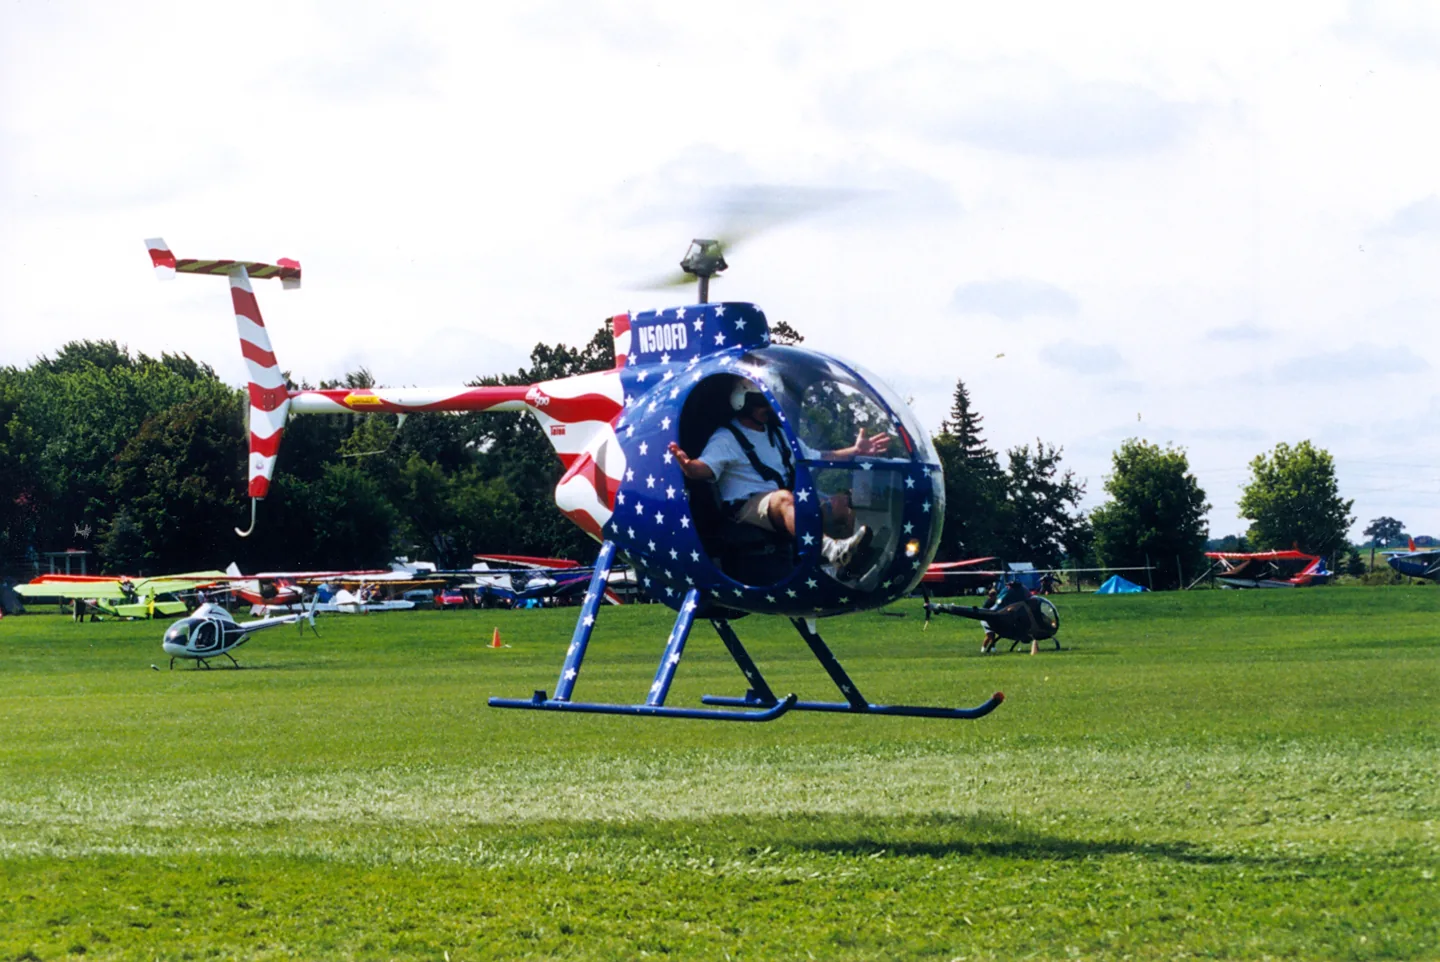
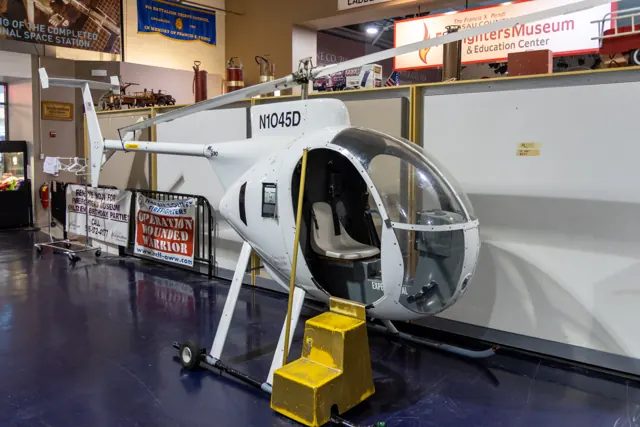
Dennis Fetters developed the single-seat Mini-500 as a homebuilt helicopter in the 1990s. The design has a compact cabin and light rotor system.
Aircraft background
VSKYLABS · Read more ↗Engine and rotor management
The simulation includes manual engine and rotor-speed management and low rotor inertia. The developer describes using recordings of Mini-500 engine and rotor sounds.
Mini-500 · VSKYLABS · X-Plane 11 · X-Plane 12
VSKYLABS · Read more ↗Into the cockpit
 YouTube
Dennis Fetters · 17 min ·
The Latest Revolution Mini-500 Helicopter Demo Video (Full Length)
The Mini-500's designer presents the Bravo kit helicopter in an original company demonstration.
Real aircraft · Revolution Mini-500
Watch on YouTube ↗Preview images are served by AirframeDB. Videos open on YouTube only when you choose to watch.
Meet Revolution Mini-500
Dennis Fetters developed the single-seat Mini-500 as a homebuilt helicopter in the 1990s. The design has a compact cabin and light rotor system.
VSKYLABS models low rotor inertia and manual engine and rotor-speed management. The developer describes research with helicopter pilots and sound recorded from the aircraft as part of its development work.
Revolution Mini-500
Aircraft type designators
A model-specific ICAO or FAA designator has not been confirmed in the references reviewed for this aircraft.
History & design
A kit helicopter from the 1990s
Dennis Fetters designed the single-seat Revolution Mini-500 as a kit helicopter. VSKYLABS identifies the 1990s design as the subject of its project and credits information from the designer, while keeping the simulation independent of Fetters Aerospace.
VSKYLABS · VSKYLABS Aerospace Simulations Aircraft Center: VSKYLABS 'Test-Pilot': Mini-500 ↗VSKYLABS Mini-500, X-Plane 12 handbook rev.005
The X-Plane development
VSKYLABS dates its Mini-500 work to 2019. The project concentrates on the light helicopter’s rotor behavior, including low rotor inertia, autorotation and the relationship between collective demand and RPM. These are the developer’s modelling aims, not independent physical qualification of this Bridge profile.
VSKYLABS · VSKYLABS Aerospace Simulations Aircraft Center: VSKYLABS 'Test-Pilot': Mini-500 ↗VSKYLABS Mini-500, X-Plane 12 handbook rev.005
Systems & details
Manual throttle or an optional governor
The handbook allows manual management of engine and rotor RPM. It also provides a simulator governor that maintains nominal rotor speed once throttle is above roughly 70–80 percent, supporting hardware without separate helicopter controls. This is an option in the VSKYLABS model; it must not be assumed to describe every Mini-500 installation or the separate MSFS add-on.
In your simulator
Systems, equipment and documentation for each developer’s aircraft.
Compare simulator versions →X-Plane 11 · X-Plane 12Mini-500
VSKYLABS · Released
Mini-500
VSKYLABS · Released
MSFS 2020 · MSFS 2024Mini-500
Got Friends · Released
Mini-500
Got Friends · Released
Manuals & resources
Find your next read
Choose a topic for a short introduction and a link to the original source. Simulator references identify the developer and edition they cover.
Simulator documentation
Engine and rotor managementMini-500 · VSKYLABS · X-Plane 11 · X-Plane 12
The simulation includes manual engine and rotor-speed management and low rotor inertia. The developer describes using recordings of Mini-500 engine and rotor sounds.
Official developer / designated-store reference · checked 2026-09-14
VSKYLABS · Read the source ↗Developer documentation
Mini-500 — product listingMini-500 · MSFS 2020 · MSFS 2024
Product listing captured 2026-09-30; edition scope from the reviewed catalogue
Got Friends · Read the source ↗Read the original documentation from the people who created it. Manuals open on their publisher’s website.
Developer documentation
VSKYLABS Aerospace Simulations Aircraft Center: VSKYLABS 'Test-Pilot': Mini-500VSKYLABS · Official developer / designated-store reference · checked 2026-09-14 VSKYLABS Revolution Mini-500 add-on for X-Plane Flight Simulator.VSKYLABS · Official developer / designated-store reference · checked 2026-09-14 mini500 Pilot Operating HandbookVSKYLABS · X-Plane 12 simulation handbook rev.005, issued March 2023; specification and optional governorProduct
Mini-500 – Got FriendsGot Friends · Product listing captured 2026-09-30; edition scope from the reviewed catalogueBuilt-in force-feedback profiles
Read the documentary basis, editable starting settings and remaining questions for the aircraft you fly. Each explanation refers to the exact profile revision shown.
Catalogue programme-20261022-v1 · 3 profile choices
Got Friends Mini-500 Turbine
Got Friends · Free and Pro · Revision 4 · Inherited starting point
MSFS 2020 · MSFS 2024
Got Friends Mini-500 Turbine: Unboosted cyclic linkage motivates light supported centering.
VSKYLABS Revolution Mini-500
VSKYLABS · Free and Pro · Revision 2 · Inherited starting point
X-Plane 12
VSKYLABS Revolution Mini-500: Unboosted cyclic linkage motivates light supported centering.
Revolution Mini-500
Free and Pro · Revision 1 · Partial review
X-Plane 12 · X-Plane 11
Revolution Mini-500: Unboosted cyclic linkage motivates light supported centering.
Revolution Mini-500
Revolution Mini-500: Unboosted cyclic linkage motivates light supported centering.
Aircraft and simulator scope
- Revolution Mini-500 · X-Plane 12 · family starting point
- Revolution Mini-500 · X-Plane 11 · family starting point
Revolution Mini-500 · Family sources identify only the variants and product versions described above.
The simulator model and controls
Dennis Fetters developed the single-seat Mini-500 as a homebuilt helicopter in the 1990s. The design has a compact cabin and light rotor system.
This starting point selects Revolution Mini-500. Its aircraft-level settings do not select a particular developer’s custom systems.
How this profile feels
Unboosted cyclic linkage motivates light supported centering. Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load. Cyclic damping adds resistance to hardware motion.
Rotor trim is separate from the governor and rotor brake. Local force trim is off. Autopilot following is off.
Controls and trim
The reviewed Mini-500 rendition uses a Solar turbine rather than the original Rotax piston engine. Its unboosted push-pull cyclic, two-blade rotor and skids have separately described rotor trim, governor and brake controls.
About the values
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
What the documentation establishes
Recovered developer page identifies Mini 500 XP12 v3.2.1.
Developer identifies single-seat kit helicopter and manual engine/rotor RPM management.
Documentary review and sources
These decisions describe the documentary basis and remaining gaps for this revision. Aircraft documentation and a starting setting describe different kinds of evidence.
Aircraft and variant
ReviewedThis starting point selects Revolution Mini-500. Its aircraft-level settings do not select a particular developer’s custom systems.
Flight controls
Not yet reviewedThe reviewed Mini-500 rendition uses a Solar turbine rather than the original Rotax piston engine. Its unboosted push-pull cyclic, two-blade rotor and skids have separately described rotor trim, governor and brake controls.
Trim
Not yet reviewedRotor trim is separate from the governor and rotor brake. Local force trim is off. Autopilot following is off.
Autopilot and stability
Not yet reviewedAutopilot following is off; the configured spring and load retain the hardware feel.
Equipment
ReviewedGear, flap and ground cues follow the selected settings and available simulator-reported states.
Speeds and limits
Not yet reviewedThe indicated-speed references set the profile response scale; they are separate from aircraft operating limits.
Simulator integration
Not yet reviewedThe profile targets xplane12, xplane11. Add-on-specific controls use only the supported references configured by this profile.
Force-feedback settings
Not yet reviewedThe settings define the profile’s effect balance. Device output limits affect physical hand force.
Starting settings and their rationale
These configured values are starting estimates. The explanations describe what each setting controls; physical validation appears separately below.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring strength | Starting value0 | What it controls and whyUnboosted cyclic linkage motivates light supported centering. The baseline spring is 0. Its low-speed blend reaches baseline strength at 40 KIAS. |
| Master force gain | Starting value0.85 | What it controls and whyScales overall profile strength while preserving effect balance, subject to device and output limits. |
| Profile force gain | Starting value0.35 | What it controls and whyThe aerodynamic-load gain is 0.35 with an indicated-speed reference of 80 KIAS. This supplies speed-dependent loading alongside the spring. |
| Force tuning speed/reference | Starting value80.0 kt | What it controls and whySets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Spring response reference speed | Starting value40.0 kt | What it controls and whySets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Aileron force scale | Starting value1 | What it controls and whyRoll and pitch aerodynamic scales are 1 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | Starting value1 | What it controls and whyScales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Trim feel | Starting valueDisabled | What it controls and whyRetained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| Trim relief | Starting valueDisabled | What it controls and whyAllows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| Autopilot follow | Starting valueDisabled | What it controls and whyAutopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot neutral hold | Starting valueDisabled | What it controls and whyPermits centering hold during a supported AP state, separate from following a moving target. |
| Output force limit | Starting value0.55 | What it controls and whyCaps directed-force output. Native spring effects and device limits remain separate. |
All 44 starting settings and their rationale
The settings define the profile’s effect balance. Device output limits affect physical hand force.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring strength | Starting value0 | What it controls and whyUnboosted cyclic linkage motivates light supported centering. The baseline spring is 0. Its low-speed blend reaches baseline strength at 40 KIAS. |
| Spring deadband | Starting value0.02 | What it controls and whySets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Profile force gain | Starting value0.35 | What it controls and whyThe aerodynamic-load gain is 0.35 with an indicated-speed reference of 80 KIAS. This supplies speed-dependent loading alongside the spring. |
| Master force gain | Starting value0.85 | What it controls and whyScales overall profile strength while preserving effect balance, subject to device and output limits. |
| QBlend Enabled | Starting valueEnabled | What it controls and whyAllows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| QSpring Minimum Factor | Starting value1 | What it controls and whySets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| QSpring Start Knots | Starting value11.2 kt | What it controls and whySets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring response reference speed | Starting value40.0 kt | What it controls and whySets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Force tuning speed/reference | Starting value80.0 kt | What it controls and whySets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening gain | Starting value0 | What it controls and whyAdds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase. |
| Airspeed spring stiffening limit | Starting value5 | What it controls and whyLimits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | Starting value1 | What it controls and whyRoll and pitch aerodynamic scales are 1 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | Starting value1 | What it controls and whyScales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Output force limit | Starting value0.55 | What it controls and whyCaps directed-force output. Native spring effects and device limits remain separate. |
| Trim feel | Starting valueDisabled | What it controls and whyRetained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| Trim relief | Starting valueDisabled | What it controls and whyAllows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| Elevator Authority | Starting value0.3 | What it controls and whyScales supported pitch-trim relief and permitted centre movement. Zero removes pitch response. |
| Aileron Authority | Starting value0.3 | What it controls and whyScales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| Force Trim Enabled | Starting valueDisabled | What it controls and whyRotor trim is separate from the governor and rotor brake. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral. |
| GLoad Enabled | Starting valueDisabled | What it controls and whyAllows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| Rate Damping Enabled | Starting valueEnabled | What it controls and whyEnables rate damping with the configured coefficients and control law. |
| Autopilot follow | Starting valueDisabled | What it controls and whyAutopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot follow authority | Starting value0.05 | What it controls and whySets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot neutral hold | Starting valueDisabled | What it controls and whyPermits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot neutral hold strength | Starting value0.6 | What it controls and whySets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Enabled | Starting valueEnabled | What it controls and whyEnables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Gain | Starting value0 | What it controls and whySets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Gain | Starting value0 | What it controls and whySets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Gain | Starting value0 | What it controls and whySets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Maximum flap index | Starting value1 | What it controls and whySets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Minimum flap index | Starting value1 | What it controls and whySets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Gain | Starting value0 | What it controls and whySets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Shaker Enabled | Starting valueDisabled | What it controls and whyPermits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Stick shaker amplitude | Starting value0.5 | What it controls and whySets triggered shaker strength; inactive while the shaker feature is disabled. |
| Enabled | Starting valueEnabled | What it controls and whyEnables ground effects; each still needs its own strength and contact or motion telemetry. |
| Gain | Starting value0 | What it controls and whySets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Gain | Starting value0 | What it controls and whySets gear-bump texture during ground motion, separate from touchdown impact. |
| Gain | Starting value0.5 | What it controls and whySets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Gain | Starting value0 | What it controls and whySets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Enabled | Starting valueEnabled | What it controls and whyEnables engine cues with nonzero settings and valid running-engine telemetry. |
| Gain | Starting value0.12 | What it controls and whySets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Enabled | Starting valueEnabled | What it controls and whyEnables accessory cues with configured strengths and observed accessory movement. |
| Gain | Starting value0 | What it controls and whySets texture from observed flap movement; a command without movement does not establish the cue. |
| Gain | Starting value0 | What it controls and whySets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
Limits and open questions
- Raw control response and low rotor inertia claims do not establish cyclic gearing.
- No magnetic-brake installation was established.
- Follow is off; no fitted servo system was established.
- No IAS hand-force schedule was established.
- Native XP12 physics claims do not verify rotor/sink feedback signals.
- Low inertia, mast-bumping and nose-tuck behavior stay simulator physics, not calibrated force cues.
Physical validation
No physical force validation is recorded in this public catalogue for this revision. Documentary review and software checks do not establish how a particular device feels.
Discuss this aircraft (0)
Questions, observations and useful sources from the community.
No published discussions yet. Bring a question or share a useful source.
Open aircraft discussions →Content expanded · What’s new
Something missing or a source that needs attention?
Suggest a correction ↗