Start here
A few places to begin, from the aircraft’s story to the people who fly it.
Meet the aircraft
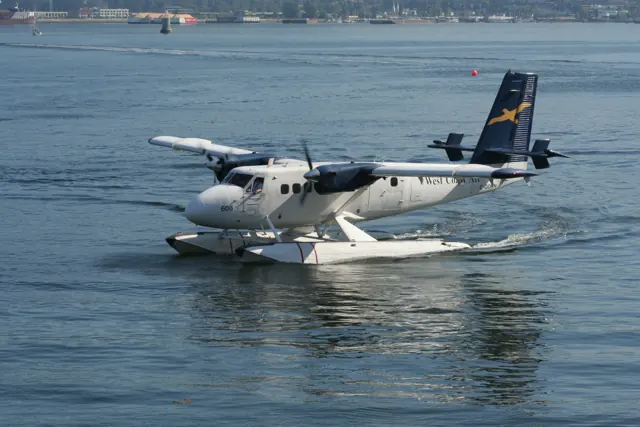
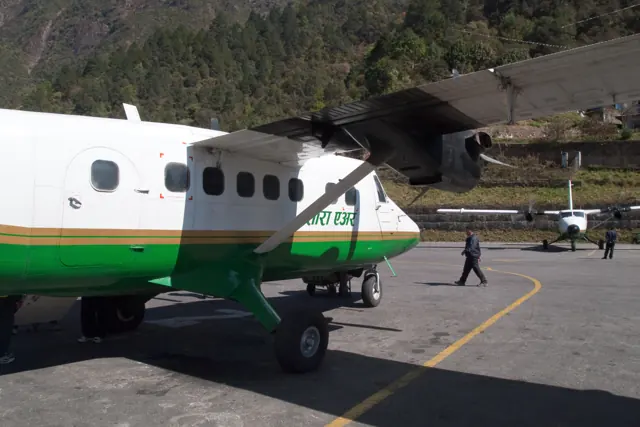
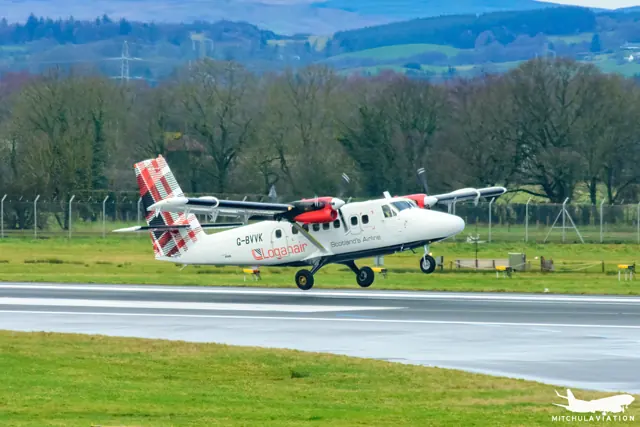
The Twin Otter was developed in the 1960s around short-field utility work. Two turboprops, a high wing and a substantial cabin support passenger and freight operations. Its fixed gear can be replaced or supplemented by specialist wheel, ski and float configurations. Production resumed under Viking before the programme returned to the De Havilland Canada name.
Aircraft background
Wikipedia contributors · Read more ↗A winter rescue at the South Pole
Loutitt’s Twin Otter work took him far beyond ordinary airport schedules. When an Antarctic station needed a medical evacuation in winter, his crew loaded fuel and equipment and headed south. This was already his second such rescue, following a previous mission to collect the station doctor. His earlier bush flying had included unprepared strips and frozen lakes.
AOPA Pilot interview by Phil Scott · February 2005. Kenn Borek Air rescue flight with copilot Brian Crocker and flight engineer Kevin Riehl; the article also recalls Loutitt’s earlier 2001 mission.
AOPA Pilot · Read more ↗Fuel controls include documented simulation limits
The guide describes main-tank boost pumps, standby pumps and wing-tank transfer controls. It explicitly marks the boost-pump TEST position as not simulated. It also says the intake deflectors move visually while their further effects are not modelled, as described for this version.
DHC-6 Twin Otter · Microsoft Flight Simulator · MSFS 2024
Microsoft / aircraft developers · Read more ↗Into the cockpit
 YouTube
AeroProductions. · 12 min ·
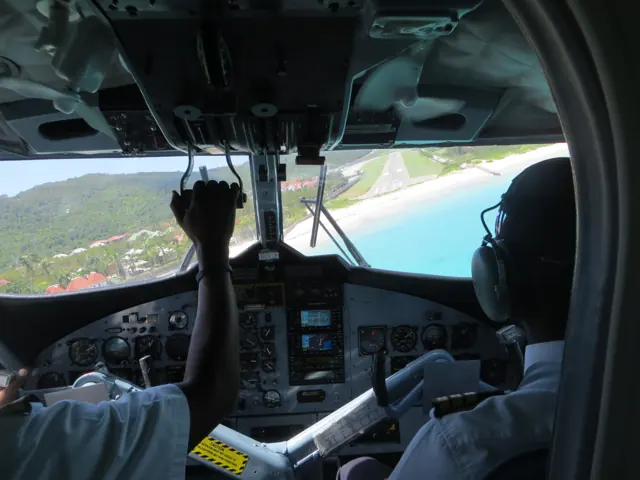
Flying in a "Twin Otter" De Havilland Canada DHC-6-300 over the see • COCKPIT VIEW • Isles of Scilly
An Isles of Scilly Twin Otter flight, seen from the cockpit.
Real aircraft · DHC-6-300
Watch on YouTube ↗Preview images are served by AirframeDB. Videos open on YouTube only when you choose to watch.
Meet De Havilland Canada DHC-6 Twin Otter
The Twin Otter was developed in the 1960s around short-field utility work. Two turboprops, a high wing and a substantial cabin support passenger and freight operations. Its fixed gear can be replaced or supplemented by specialist wheel, ski and float configurations.
Production resumed under Viking before the programme returned to the De Havilland Canada name. Different series and later developments have their own engines and avionics. The simulator packages identify their series and cockpit generation.
De Havilland Canada DHC-6 Twin Otter
De Havilland Canada → · Explore the family →
De Havilland Canada DHC-6 Twin Otter
Wikipedia contributors · De Havilland Canada DHC-6 Twin Otter ↗Microsoft Flight Simulator · MSFS 2024 →Aircraft type designators
Use the code for the model you are flying. The linked authority lists the applicable aircraft.
De Havilland Canada DHC-6 Twin Otter
ICAO Doc 8643 — aircraft type designators ↗Checked 2026-09-14History & design
An airframe adapted to many different jobs
De Havilland Canada’s Series 400 description offers interiors for passenger services, cargo, medical evacuation and special missions. Reconfigurable cabins and a choice of landing equipment allow the same family to serve island communities, remote bases and conventional airports. The role can change substantially with the operator and equipment.
De Havilland Canada · Twin Otter Series 400 ↗Manufacturer’s Series 400 description
Cockpit generation matters alongside the familiar shape
The Series 400 product description specifies Honeywell Apex avionics, illustrating a later cockpit within the Twin Otter family. Its Guardian derivative adds mission-specific configurations. Those aircraft should be distinguished from earlier Series 300 machines when comparing pilot accounts and the particular model represented by an add-on.
De Havilland Canada · Twin Otter Series 400 ↗Manufacturer’s Series 400 and Guardian descriptions; no claim that this page describes every current Twin Otter version
Development milestones
First flight: 20 May 1965
Developed from: de Havilland Canada DHC-3 Otter
Wikipedia contributors · De Havilland Canada DHC-6 Twin Otter ↗De Havilland Canada DHC-6 Twin Otter · family/variant named by the source · Wikipedia revision 1369791029
Pilot accounts
A winter rescue at the South Pole
Loutitt’s Twin Otter work took him far beyond ordinary airport schedules. When an Antarctic station needed a medical evacuation in winter, his crew loaded fuel and equipment and headed south. This was already his second such rescue, following a previous mission to collect the station doctor. His earlier bush flying had included unprepared strips and frozen lakes.
The polar leg depended on a heavily fuelled aircraft and offered little room to divert. He eventually picked out the drums burning beside the snow runway and landed. After rest and refuelling, the crew departed with their patient, staged through the northern Antarctic region and continued to Chile for medical care. The interview describes the aircraft as part of a carefully organised crew effort across an exceptionally isolated route.
AOPA Pilot interview by Phil Scott · February 2005. Kenn Borek Air rescue flight with copilot Brian Crocker and flight engineer Kevin Riehl; the article also recalls Loutitt’s earlier 2001 mission.
Read the full account · AOPA Pilot ↗Investigating ice from the research cockpit
Ranaudo describes a programme that progressed from measuring icing clouds to understanding what ice did to aircraft performance and control. The Twin Otter carried additional protection, cameras and instruments so the researchers could connect the conditions outside with the aircraft’s response. Later work used artificial ice shapes and a gradual series of increasingly demanding tests.
One test he recounts produced pulsing elevator forces, pitch oscillations and then an abrupt nose-down motion that briefly made the crew weightless. Recovery followed rapidly, but the episode captured how physically demanding the problem could become. His account emphasises the preparation and incremental testing behind that moment. These observations belong to a specially configured research aircraft and its test programme; they do not establish how a desktop simulator models icing.
Flight Safety Foundation · February 2017. Retrospective by NASA’s former lead icing research pilot, describing the team’s modified Twin Otter and controlled flight-test programme.
Read the full account · Flight Safety Foundation / AeroSafety World ↗Flying the science mission includes digging out the fuel
Below describes Twin Otter flying as one part of a much larger field operation. Pilots work closely with scientists to deploy teams, supply their camps and bring them home. Some assignments mean living in tents on the ice alongside the people they support. The aircraft’s retractable skis connect Rothera’s gravel runway with remote snowfields.
Keeping those flights possible also means maintaining a scattered network of fuel depots. Drums may move with the ice beneath them and become buried by winter snowfall, leaving a marker to guide the search. Digging them out becomes a pilot’s task as well. Below finds the combination of demanding flying, unfamiliar landing areas and practical support work deeply satisfying because it contributes directly to scientific understanding of the continent.
Royal Air Force Charitable Trust · April 2024. British Antarctic Survey DHC-6-300 operations from Rothera during the austral summer.
Read the full account · Royal Air Force Charitable Trust ↗In your simulator
Systems, equipment and documentation for each developer’s aircraft.
Compare simulator versions →MSFS 2024DHC-6 Twin Otter
Microsoft Flight Simulator · Released
DHC-6 Twin Otter
Microsoft Flight Simulator · Released
X-Plane 12DHC-6 Twin Otter 300 Series v2
RWDesigns · Released
DHC-6 Twin Otter 300 Series v2
RWDesigns · Released
Manuals & resources
Find your next read
Choose a topic for a short introduction and a link to the original source. Simulator references identify the developer and edition they cover.
Simulator documentation
Fuel controls include documented simulation limitsDHC-6 Twin Otter · Microsoft Flight Simulator · MSFS 2024
The guide describes main-tank boost pumps, standby pumps and wing-tank transfer controls. It explicitly marks the boost-pump TEST position as not simulated. It also says the intake deflectors move visually while their further effects are not modelled, as described for this version.
Archived MSFS 2024 AOM · PDF pp.22–25
Microsoft / aircraft developers · Read the source ↗Navigation assistance still leaves speed with the pilotDHC-6 Twin Otter · Microsoft Flight Simulator · MSFS 2024
The documented autopilot offers heading, navigation, approach, altitude and vertical-speed modes, including capture of a selected altitude. Approach mode follows the localiser and glideslope; the guide expressly distinguishes this from autoland and provides no automatic throttle or speed control.
Archived MSFS 2024 AOM · PDF pp.35–36
Microsoft / aircraft developers · Read the source ↗The Twin Otter's working cockpitDHC-6 Twin Otter · Microsoft Flight Simulator · MSFS 2024
The aircraft operating manual identifies the armrest-mounted autopilot controls, trim and flap indications, and hydraulic-pressure instrumentation.
Archived simulator manual; installed package revision not observed · PDF pp.7,11,21
Microsoft / aircraft developers · Read the source ↗Wheels, skis and amphibious floatsDHC-6 Twin Otter · Microsoft Flight Simulator · MSFS 2024
The MSFS 2024 manual identifies a Series 300 package with wheeled, ski and amphibious versions. The amphibian adds a panel gear lever and individual wheel-position lights: green for lowered wheels and blue for raised wheels. Its loading and centre-of-gravity limits are treated separately in the guide.
Archived MSFS 2024 AOM · PDF pp.4,37; installed package revision not observed
Microsoft / aircraft developers · Read the source ↗Pilot account
A winter rescue at the South PoleAOPA Pilot interview by Phil Scott · February 2005. Kenn Borek Air rescue flight with copilot Brian Crocker and flight engineer Kevin Riehl; the article also recalls Loutitt’s earlier 2001 mission.
Loutitt’s Twin Otter work took him far beyond ordinary airport schedules. When an Antarctic station needed a medical evacuation in winter, his crew loaded fuel and equipment and headed south. This was already his second such rescue, following a previous mission to collect the station doctor. His earlier bush flying had included unprepared strips and frozen lakes. The polar leg depended on a heavily fuelled aircraft and offered little room to divert.
Sean Loutitt
AOPA Pilot · Read the source ↗Investigating ice from the research cockpitFlight Safety Foundation · February 2017. Retrospective by NASA’s former lead icing research pilot, describing the team’s modified Twin Otter and controlled flight-test programme.
Ranaudo describes a programme that progressed from measuring icing clouds to understanding what ice did to aircraft performance and control. The Twin Otter carried additional protection, cameras and instruments so the researchers could connect the conditions outside with the aircraft’s response. Later work used artificial ice shapes and a gradual series of increasingly demanding tests.
Richard J. Ranaudo
Flight Safety Foundation / AeroSafety World · Read the source ↗Developer documentation
DHC-6 Twin Otter 300 Series v2 — product listingDHC-6 Twin Otter 300 Series v2 · X-Plane 12
Product listing captured 2026-09-24; edition scope from the reviewed catalogue
RWDesigns · Read the source ↗Read the original documentation from the people who created it. Manuals open on their publisher’s website.
Manual
DH-6 Twin Otter AOMMicrosoft / aircraft developers Microsoft Flight Simulator aircraft manualsMicrosoft / aircraft developersAircraft background
De Havilland Canada DHC-6 Twin OtterWikipedia contributors · Research background · Wikipedia revision 1369791029 · retrieved 2026-09-12 Twin Otter Series 400De Havilland Canada · Manufacturer’s Series 400 product description · retrieved September 2026Resource
MSFS 2024 FAQ and edition aircraft inventoryMicrosoftType designator
ICAO Doc 8643 — aircraft type designatorsInternational Civil Aviation Organization · Public search data retrieved 2026-09-14; authority update 2026-09-03Product
DHC-6 Twin Otter 300 Series v2RWDesigns · Product listing captured 2026-09-24; edition scope from the reviewed catalogueBuilt-in force-feedback profiles
Read the documentary basis, editable starting settings and remaining questions for the aircraft you fly. Each explanation refers to the exact profile revision shown.
Catalogue programme-20261022-v1 · 7 profile choices
RWDesigns DHC-6-300 Floats (community XP12 patch)
RWDesigns · Free and Pro · Revision 3 · Inherited starting point
X-Plane 12
RWDesigns DHC-6-300 Floats (community XP12 patch): The selected yoke resistance accompanies the particular Twin Otter configuration.
RWDesigns DHC-6-300 Skis (community XP12 patch)
RWDesigns · Free and Pro · Revision 3 · Inherited starting point
X-Plane 12
RWDesigns DHC-6-300 Skis (community XP12 patch): The selected yoke resistance accompanies the particular Twin Otter configuration.
RWDesigns DHC-6-300 Tundra (community XP12 patch)
RWDesigns · Free and Pro · Revision 3 · Inherited starting point
X-Plane 12
RWDesigns DHC-6-300 Tundra (community XP12 patch): The selected yoke resistance accompanies the particular Twin Otter configuration.
RWDesigns DHC-6-300 Wheels (community XP12 patch)
RWDesigns · Free and Pro · Revision 3 · Inherited starting point
X-Plane 12
RWDesigns DHC-6-300 Wheels (community XP12 patch): The selected yoke resistance accompanies the particular Twin Otter configuration.
De Havilland DHC-6-300 Twin Otter (wheels)
Free and Pro · Revision 3 · Partial review
MSFS 2024
De Havilland DHC-6-300 Twin Otter (wheels): The selected yoke resistance accompanies the particular Twin Otter configuration.
De Havilland DHC-6-300 Twin Otter (floats)
Free and Pro · Revision 1 · Partial review
MSFS 2024
De Havilland DHC-6-300 Twin Otter (floats): The selected yoke resistance accompanies the particular Twin Otter configuration.
De Havilland DHC-6-300 Twin Otter (skis)
Free and Pro · Revision 1 · Partial review
MSFS 2024
De Havilland DHC-6-300 Twin Otter (skis): The selected yoke resistance accompanies the particular Twin Otter configuration.
RWDesigns DHC-6-300 Wheels (community XP12 patch)
RWDesigns DHC-6-300 Wheels (community XP12 patch): The selected yoke resistance accompanies the particular Twin Otter configuration.
Aircraft and simulator scope
- RWDesigns DHC-6-300 Wheels (community XP12 patch) · RWDesigns · X-Plane 12 · Add-on starting point
The simulator model and controls
The Twin Otter was developed in the 1960s around short-field utility work. Two turboprops, a high wing and a substantial cabin support passenger and freight operations. Its fixed gear can be replaced or supplemented by specialist wheel, ski and float configurations.
This profile selects RWDesigns DHC-6-300 Wheels (community XP12 patch) for X-Plane 12.
How this profile feels
The selected yoke resistance accompanies the particular Twin Otter configuration. Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.
Trim relief is configured separately from nose length and landing-gear fit. Pitch-trim relief is off. Autopilot following is off.
Controls and trim
RWDesigns separates short- and long-nose Twin Otters and four landing-gear fits. Its original V2 aircraft is an XP11 generation with an unofficial XP12 patch. The patch and surface options retain their own implementation scope within the turboprop utility family.
The selected implementation
These configurations use an unofficial XP12 patch on RWDesigns’ original V2 generation, with separate nose/gear choices.
About the values
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
Documentary review and sources
These decisions describe the documentary basis and remaining gaps for this revision. Aircraft documentation and a starting setting describe different kinds of evidence.
Aircraft and variant
InheritedThis profile selects RWDesigns DHC-6-300 Wheels (community XP12 patch) for X-Plane 12.
Flight controls
InheritedRWDesigns separates short- and long-nose Twin Otters and four landing-gear fits. Its original V2 aircraft is an XP11 generation with an unofficial XP12 patch. The patch and surface options retain their own implementation scope within the turboprop utility family.
Trim
InheritedTrim relief is configured separately from nose length and landing-gear fit. Pitch relief is off, with stored authority 0; roll authority is 0.
Autopilot and stability
InheritedAutopilot following is off; the configured spring and load retain the hardware feel.
Equipment
InheritedThese configurations use an unofficial XP12 patch on RWDesigns’ original V2 generation, with separate nose/gear choices.
Speeds and limits
InheritedThe indicated-speed references set the profile response scale; they are separate from aircraft operating limits.
Simulator integration
InheritedThe profile targets xplane12. Add-on-specific controls use only the supported references configured by this profile.
Force-feedback settings
InheritedThe settings define the profile’s effect balance. Device output limits affect physical hand force.
Starting settings and their rationale
These configured values are starting estimates. The explanations describe what each setting controls; physical validation appears separately below.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring strength | Starting value0.74 | What it controls and whyThe selected yoke resistance accompanies the particular Twin Otter configuration. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 65 KIAS. |
| Master force gain | Starting value0.85 | What it controls and whyScales overall profile strength while preserving effect balance, subject to device and output limits. |
| Profile force gain | Starting value0.8 | What it controls and whyThe aerodynamic-load gain is 0.8 with an indicated-speed reference of 130 KIAS. This supplies speed-dependent loading alongside the spring. |
| Force tuning speed/reference | Starting value130 kt | What it controls and whySets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Spring response reference speed | Starting value65 kt | What it controls and whySets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Aileron force scale | Starting value0.72 | What it controls and whyRoll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | Starting value1.0 | What it controls and whyScales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Trim feel | Starting valueDisabled | What it controls and whyRetained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| Trim relief | Starting valueDisabled | What it controls and whyAllows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| Autopilot follow | Starting valueDisabled | What it controls and whyAutopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot neutral hold | Starting valueDisabled | What it controls and whyPermits centering hold during a supported AP state, separate from following a moving target. |
| Output force limit | Starting value0.55 | What it controls and whyCaps directed-force output. Native spring effects and device limits remain separate. |
All 44 starting settings and their rationale
The settings define the profile’s effect balance. Device output limits affect physical hand force.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring strength | Starting value0.74 | What it controls and whyThe selected yoke resistance accompanies the particular Twin Otter configuration. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 65 KIAS. |
| Spring deadband | Starting value0.04 | What it controls and whySets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Profile force gain | Starting value0.8 | What it controls and whyThe aerodynamic-load gain is 0.8 with an indicated-speed reference of 130 KIAS. This supplies speed-dependent loading alongside the spring. |
| Master force gain | Starting value0.85 | What it controls and whyScales overall profile strength while preserving effect balance, subject to device and output limits. |
| QBlend Enabled | Starting valueEnabled | What it controls and whyAllows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| QSpring Minimum Factor | Starting value0.55 | What it controls and whySets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| QSpring Start Knots | Starting value8 kt | What it controls and whySets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring response reference speed | Starting value65 kt | What it controls and whySets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Force tuning speed/reference | Starting value130 kt | What it controls and whySets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening gain | Starting value0.15 | What it controls and whyThe high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 65 KIAS, with the squared-speed ratio capped at 5. |
| Airspeed spring stiffening limit | Starting value5 | What it controls and whyLimits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | Starting value0.72 | What it controls and whyRoll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | Starting value1.0 | What it controls and whyScales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Output force limit | Starting value0.55 | What it controls and whyCaps directed-force output. Native spring effects and device limits remain separate. |
| Trim feel | Starting valueDisabled | What it controls and whyRetained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| Trim relief | Starting valueDisabled | What it controls and whyAllows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| Elevator Authority | Starting value0 | What it controls and whyTrim relief is configured separately from nose length and landing-gear fit. Pitch relief is off, with stored authority 0; roll authority is 0. |
| Aileron Authority | Starting value0 | What it controls and whyScales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| Force Trim Enabled | Starting valueDisabled | What it controls and whyEnables local force trim, separate from aircraft-owned trim and add-on integration qualification. |
| GLoad Enabled | Starting valueEnabled | What it controls and whyAllows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| Rate Damping Enabled | Starting valueEnabled | What it controls and whyEnables rate damping with the configured coefficients and control law. |
| Autopilot follow | Starting valueDisabled | What it controls and whyAutopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot follow authority | Starting value0.1 | What it controls and whySets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot neutral hold | Starting valueDisabled | What it controls and whyPermits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot neutral hold strength | Starting value0.6 | What it controls and whySets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Enabled | Starting valueEnabled | What it controls and whyEnables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Gain | Starting value0.35 | What it controls and whySets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Gain | Starting value0 | What it controls and whySets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Gain | Starting value0 | What it controls and whySets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Maximum flap index | Starting value3 | What it controls and whySets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Minimum flap index | Starting value2 | What it controls and whySets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Gain | Starting value0 | What it controls and whySets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Shaker Enabled | Starting valueDisabled | What it controls and whyPermits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Stick shaker amplitude | Starting value0.5 | What it controls and whySets triggered shaker strength; inactive while the shaker feature is disabled. |
| Enabled | Starting valueEnabled | What it controls and whyEnables ground effects; each still needs its own strength and contact or motion telemetry. |
| Gain | Starting value0.4 | What it controls and whySets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Gain | Starting value0.25 | What it controls and whySets gear-bump texture during ground motion, separate from touchdown impact. |
| Gain | Starting value0.65 | What it controls and whySets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Gain | Starting value0 | What it controls and whySets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Enabled | Starting valueEnabled | What it controls and whyEnables engine cues with nonzero settings and valid running-engine telemetry. |
| Gain | Starting value0.12 | What it controls and whySets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Enabled | Starting valueEnabled | What it controls and whyEnables accessory cues with configured strengths and observed accessory movement. |
| Gain | Starting value0.12 | What it controls and whySets texture from observed flap movement; a command without movement does not establish the cue. |
| Gain | Starting value0 | What it controls and whySets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
Limits and open questions
- Manual Twin Otter controls; short/long noses share the same estimated control law.
- No exact patched-aircraft trim-neutral contract established; relief off.
- No calibrated autopilot servo or inceptor-demand output established. AP follow and neutral hold are disabled.
- 130 KIAS is an estimated tuning reference, not a certified operating limit or cruise TAS.
- Native read-only aircraft telemetry only. No custom interface names, units or freshness contract invented; switches and animated controls are not servo demands.
- Spring 0.74, lateral scale 0.7, pitch/roll relief 0/0; editable estimates. No measured hand-force calibration, unsupported failure loads, surface-follow or body-rate torque.
- Installed-aircraft and physical checks are deferred. If telemetry omits the developer or configuration, select this profile and save it as the aircraft default.
- Only actual accessory-position changes drive movement textures. No release or installed-product acceptance is inferred.
Physical validation
No physical force validation is recorded in this public catalogue for this revision. Documentary review and software checks do not establish how a particular device feels.
Discuss this aircraft (0)
Questions, observations and useful sources from the community.
No published discussions yet. Bring a question or share a useful source.
Open aircraft discussions →Content expanded · What’s new
Something missing or a source that needs attention?
Suggest a correction ↗