Start here
A few places to begin, from the aircraft’s story to the people who fly it.
Meet the aircraft
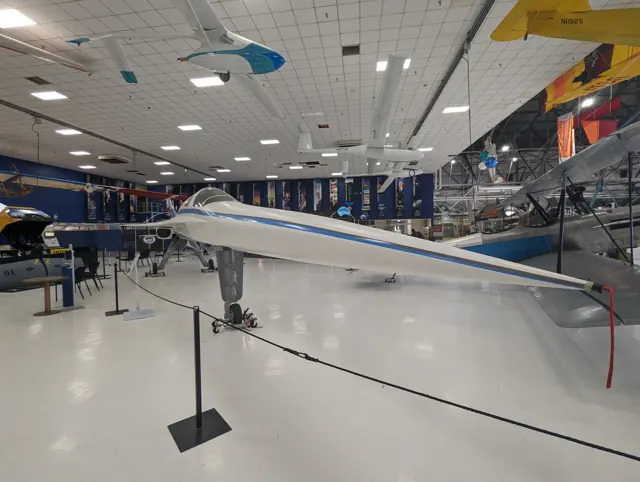
Boom's XB-1 is an experimental demonstrator for the Overture programme. Its slender fuselage and highly swept wing are paired with three General Electric J85 engines. The demonstrator first flew in March 2024 and reached supersonic flight during its 2025 test programme. Its value in a simulator is the chance to examine a specialised experimental cockpit and an unusual flight envelope.
Aircraft background
Wikipedia contributors · Read more ↗The first flight requires a sceptic to become ready to go
Shoemaker described a change in outlook as XB-1 approached its first flight. During development, he had to question assumptions and encourage the team to imagine how the aircraft might behave. Lined up on the runway, he needed confidence that those concerns had been addressed and that the people supporting him were ready. That confidence still allowed for surprises.
Boom interview · April 2024, after XB-1’s first flight. Shoemaker flew the demonstrator; Brandenburg flew the T-38 chase aircraft on that occasion.
Boom Supersonic · Read more ↗Fuel quantities also need cockpit entry
Cold starts need initial and Bingo fuel in thousands of pounds on OVR or ENS; runway starts prepopulate them.
Boom XB-1 · Microsoft Flight Simulator · MSFS 2024
Microsoft / aircraft developers · Read more ↗Into the cockpit
 YouTube
Boom Supersonic · 25 min ·
Inside the Cockpit of Boom Supersonic's XB-1
Boom's flight-test engineer narrates the XB-1's tenth test flight.
Real aircraft · Boom XB-1
Watch on YouTube ↗ YouTube
Boom Supersonic · 21 min ·
Go Inside the Cockpit: XB-1 Flight 4 Full Video Narrated by Nick Sheryka—Chief Flight Test Engineer
Flight-test commentary and crew communications from the XB-1's fourth flight.
Real aircraft · Boom XB-1
Watch on YouTube ↗Preview images are served by AirframeDB. Videos open on YouTube only when you choose to watch.
Meet Boom XB-1
Boom's XB-1 is an experimental demonstrator for the Overture programme. Its slender fuselage and highly swept wing are paired with three General Electric J85 engines. The demonstrator first flew in March 2024 and reached supersonic flight during its 2025 test programme.
The developer's guide describes its conventional flight controls, including the pitch-feel and roll mechanisms.
Boom XB-1
Aircraft type designators
Use the code for the model you are flying. The linked authority lists the applicable aircraft.
History & design
The supersonic flight feels smooth from the cockpit
Speaking to CNN after the 28 January 2025 flight, Brandenburg described the XB-1 as smooth at supersonic speed. He explained that the Mach indication, rather than hearing a sonic boom inside the cockpit, marked the change for him.
CNN · The Lead: interview with XB-1 pilot Tristan Brandenburg ↗Pilot’s broadcast interview; future airliner plans are separate
Development milestones
First flight: March 22, 2024
Wikipedia contributors · Boom XB-1 ↗Boom XB-1 · family/variant named by the source · Wikipedia revision 1367159153
Pilot accounts
The first flight requires a sceptic to become ready to go
Shoemaker described a change in outlook as XB-1 approached its first flight. During development, he had to question assumptions and encourage the team to imagine how the aircraft might behave. Lined up on the runway, he needed confidence that those concerns had been addressed and that the people supporting him were ready.
That confidence still allowed for surprises. He expected the real aircraft to reveal things that hundreds of simulator hours could not, and felt a strong responsibility not to let his own flying undermine the team’s preparation. The first outing deliberately kept its ambitions limited, including leaving the landing gear extended. His recollection centres on that balance between trust in the work already done and attentiveness to an unfamiliar aircraft.
Boom interview · April 2024, after XB-1’s first flight. Shoemaker flew the demonstrator; Brandenburg flew the T-38 chase aircraft on that occasion.
Read the full account · Boom Supersonic ↗Preparation helps the nerves settle after liftoff
Brandenburg could see his own nerves when he watched the cockpit recording of his first XB-1 flight. His breathing changed just before brake release, but the apprehension faded once the wheels left the ground. Time in the simulator had made the transition to the real aircraft feel unexpectedly familiar.
Preparing each briefing was another way of building confidence. Writing down the plan and explaining it to colleagues forced him to think through the flight. He also described the value of a consistent routine and a prayer at the foot of the ladder, acknowledging the people and opportunities that had brought him there. He still felt nervous before test flights, but regarded that awareness as part of taking the work seriously.
Boom interview · January 2025. His first XB-1 flight was the programme’s second flight; these recollections precede the first supersonic sortie.
Read the full account · Boom Supersonic ↗In your simulator
Systems, equipment and documentation for each developer’s aircraft.
Compare simulator versions →MSFS 2024Boom XB-1
Microsoft Flight Simulator · Released
Boom XB-1
Microsoft Flight Simulator · Released
MSFS 2024Boom XB-1
FlightFX · Released
Boom XB-1
FlightFX · Released
Aircraft specifications
Published figures for the named real-aircraft variant. Simulator equipment and performance can differ.
| Specification | Published value |
|---|---|
| Length | 68 ft (21 m) |
| Wingspan | 21 ft (6.4 m) |
| Height | 17 ft (5.2 m) |
| Max takeoff weight | 13,500 lb (6,123 kg) |
| Powerplant | 3 × GE J85-15 afterburning turbojet , 2,925 lbf (13.01 kN) thrust each dry, 4,300 lbf (19 kN) with afterburner |
| Maximum speed | Mach 1.1 |
| Range | 1,000 nmi (1,200 mi, 1,900 km) (unconfirmed) |
Manuals & resources
Find your next read
Choose a topic for a short introduction and a link to the original source. Simulator references identify the developer and edition they cover.
Simulator documentation
Fuel quantities also need cockpit entryBoom XB-1 · Microsoft Flight Simulator · MSFS 2024
Cold starts need initial and Bingo fuel in thousands of pounds on OVR or ENS; runway starts prepopulate them.
Manual page 31
Microsoft / aircraft developers · Read the source ↗Some flight-control assignments are customBoom XB-1 · Microsoft Flight Simulator · MSFS 2024
The manual requires custom pitch/yaw trim assignments, with no stock keys for Q-feel, dampers or roll deflection.
Developer-documented scope · page 95
Microsoft / aircraft developers · Read the source ↗Several test and environmental systems are omittedBoom XB-1 · Microsoft Flight Simulator · MSFS 2024
FES, oxygen, failures and cabin altitude are not simulated; a representative altitude may appear.
Manual pages 25 and 95
Microsoft / aircraft developers · Read the source ↗Pitch feel and roll response are different mechanismsBoom XB-1 · Microsoft Flight Simulator · MSFS 2024
The XB-1 guide explicitly states that the aircraft has neither an autopilot nor fly-by-wire. It distinguishes pitch Q-feel scheduling from a roll-ratio changer: the latter changes control-surface response without changing feel.
MSFS2024 XB1 manual1.0 · PDF pp.6,27-28
Microsoft / aircraft developers · Read the source ↗The forward view uses synthetic visionBoom XB-1 · Microsoft Flight Simulator · MSFS 2024
FLVS uses synthetic vision. Select FLV on the MFD with the gear extended; it is unavailable otherwise.
Manual 1.0 · pages 39–40
Microsoft / aircraft developers · Read the source ↗Tank loading and total fuel differBoom XB-1 · Microsoft Flight Simulator · MSFS 2024
The tablet permits individual tank loading; entering only a total distributes fuel evenly.
Manual page 95
Microsoft / aircraft developers · Read the source ↗Pilot account
The first flight requires a sceptic to become ready to goBoom interview · April 2024, after XB-1’s first flight. Shoemaker flew the demonstrator; Brandenburg flew the T-38 chase aircraft on that occasion.
Shoemaker described a change in outlook as XB-1 approached its first flight. During development, he had to question assumptions and encourage the team to imagine how the aircraft might behave. Lined up on the runway, he needed confidence that those concerns had been addressed and that the people supporting him were ready. That confidence still allowed for surprises.
Bill “Doc” Shoemaker
Boom Supersonic · Read the source ↗Preparation helps the nerves settle after liftoffBoom interview · January 2025. His first XB-1 flight was the programme’s second flight; these recollections precede the first supersonic sortie.
Brandenburg could see his own nerves when he watched the cockpit recording of his first XB-1 flight. His breathing changed just before brake release, but the apprehension faded once the wheels left the ground. Time in the simulator had made the transition to the real aircraft feel unexpectedly familiar. Preparing each briefing was another way of building confidence. Writing down the plan and explaining it to colleagues forced him to think through the flight.
Tristan “Geppetto” Brandenburg
Boom Supersonic · Read the source ↗Developer documentation
Boom XB-1 — product listingBoom XB-1 · MSFS 2024
Product listing captured 2026-09-24; edition scope from the reviewed catalogue
FlightFX · Read the source ↗Read the original documentation from the people who created it. Manuals open on their publisher’s website.
Manual
MSFS2024 – Microsoft – Boom XB-1 – User Manual – 1.0Microsoft / aircraft developers Microsoft Flight Simulator aircraft manualsMicrosoft / aircraft developersAircraft background
Boom XB-1Wikipedia contributors · Research background · Wikipedia revision 1367159153 · retrieved 2026-09-12 The Lead: interview with XB-1 pilot Tristan BrandenburgCNN · Broadcast transcript · 28 January 2025Resource
XB1 and UH1H free additionsMicrosoftType designator
ICAO Doc 8643 — aircraft type designatorsInternational Civil Aviation Organization · Public search data retrieved 2026-09-14; authority update 2026-09-03Product
Boom XB-1FlightFX · Product listing captured 2026-09-24; edition scope from the reviewed catalogueBuilt-in force-feedback profiles
Read the documentary basis, editable starting settings and remaining questions for the aircraft you fly. Each explanation refers to the exact profile revision shown.
Catalogue programme-20261022-v1 · 2 profile choices
FlightFX Boom XB-1
FlightFX · Free and Pro · Revision 3 · Inherited starting point
MSFS 2024
FlightFX Boom XB-1: The powered-control spring approximates artificial pitch feel; the actual Mach/altitude Q-feel schedule and roll-ratio mechanism are not reproduced by one IAS reference.
Boom XB-1
Free and Pro · Revision 1 · Partial review
MSFS 2024
Boom XB-1: The powered-control spring approximates artificial pitch feel; the actual Mach/altitude Q-feel schedule and roll-ratio mechanism are not reproduced by one IAS reference.
Boom XB-1
Boom XB-1: The powered-control spring approximates artificial pitch feel; the actual Mach/altitude Q-feel schedule and roll-ratio mechanism are not reproduced by one IAS reference.
Aircraft and simulator scope
- Boom XB-1 · MSFS 2024 · family starting point
Microsoft Boom XB-1 MSFS2024 user manual version 1.0; custom trim/feel controls are distinct from standard simulator bindings. · Selected choice: Boom XB-1. Documentary scope does not establish every variant, add-on revision or simulator binding.
The simulator model and controls
Boom's XB-1 is an experimental aircraft, not a passenger-carrying version of Overture. Its slender fuselage and highly swept wing are paired with three General Electric J85 engines. The demonstrator first flew in March 2024 and reached supersonic flight during its 2025 test programme.
This starting point selects Boom XB-1. Its aircraft-level settings do not select a particular developer’s custom systems.
How this profile feels
Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.
Valid trim provides the configured pressure relief. Autopilot following is off.
Controls and trim
The XB-1 guide explicitly describes mechanically commanded hydraulic primary controls, with no fly-by-wire or autopilot. Hydraulic actuators isolate surface airloads; programmed pitch Q-feel supplies resistance using Mach and altitude. Roll-ratio adjustment changes response displacement rather than force. The aircraft has no flaps, slats or spoilers. Its custom trim, damper and feel assignments therefore cannot be inferred from an ordinary airliner configuration.
About the values
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
What the documentation establishes
The manual explicitly states that XB-1 has no autopilot, autothrottle, FADEC, flaps/slats/spoilers or fly-by-wire.
Hydraulic actuators remove surface airloads from pilot feel. A programmed pitch Q-feel schedule supplies resistance; roll-ratio adjustment changes response, not force.
Pitch/yaw trim and feel controls are custom; standard MSFS2024 trim/feel bindings are not supported as generic ownership proof.
The manual explicitly excludes autopilot and autothrottle, supporting disabled generic following for this implementation.
Absence of flaps, slats and spoilers is explicit; gear and engine cues still remain separate numerical approximations.
The stated 160-175-knot landing range is procedure-specific, not a derivation of the preset's 300-knot indicated-speed force reference.
Documentary review and sources
These decisions describe the documentary basis and remaining gaps for this revision. Aircraft documentation and a starting setting describe different kinds of evidence.
Aircraft and variant
ReviewedThis starting point selects Boom XB-1. Its aircraft-level settings do not select a particular developer’s custom systems.
Flight controls
ReviewedThe XB-1 guide explicitly describes mechanically commanded hydraulic primary controls, with no fly-by-wire or autopilot. Hydraulic actuators isolate surface airloads; programmed pitch Q-feel supplies resistance using Mach and altitude. Roll-ratio adjustment changes response displacement rather than force. The aircraft has no flaps, slats or spoilers. Its custom trim, damper and feel assignments therefore cannot be inferred from an ordinary airliner configuration.
Trim
ReviewedCustom pitch trim is documented, but the profile's permitted centre response remains a simplified feel representation rather than a verified generic trim interface. Pitch authority 0.3 relieves permitted loading; hydraulic centre movement is off. Roll authority is 0.09.
Autopilot and stability
ReviewedAutopilot following is off; the configured spring and load retain the hardware feel.
Equipment
ReviewedGear, flap and ground cues follow the selected settings and available simulator-reported states.
Speeds and limits
ReviewedThe indicated-speed references set the profile response scale; they are separate from aircraft operating limits.
Simulator integration
ReviewedThe profile targets msfs2024. Add-on-specific controls use only the supported references configured by this profile.
Force-feedback settings
Not yet reviewedThe settings define the profile’s effect balance. Device output limits affect physical hand force.
Starting settings and their rationale
These configured values are starting estimates. The explanations describe what each setting controls; physical validation appears separately below.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring strength | Starting value0.8 | What it controls and whyThe powered-control spring approximates artificial pitch feel; the actual Mach/altitude Q-feel schedule and roll-ratio mechanism are not reproduced by one IAS reference. The baseline spring is 0.8. Its low-speed blend reaches baseline strength at 90 KIAS. |
| Master force gain | Starting value0.85 | What it controls and whyScales overall profile strength while preserving effect balance, subject to device and output limits. |
| Profile force gain | Starting value0.25 | What it controls and whyThe aerodynamic-load gain is 0.25 with an indicated-speed reference of 300 KIAS. The hydraulic-load factor of 0.35 scales that modeled term; it is a selected artificial-feel approximation. |
| Force tuning speed/reference | Starting value300.0 kt | What it controls and whySets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Spring response reference speed | Starting value90 kt | What it controls and whySets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Aileron force scale | Starting value0.65 | What it controls and whyRoll and pitch aerodynamic scales are 0.65 and 0.65, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | Starting value0.65 | What it controls and whyScales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Trim feel | Starting valueEnabled | What it controls and whyRetained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| Trim relief | Starting valueEnabled | What it controls and whyAllows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| Autopilot follow | Starting valueDisabled | What it controls and whyAutopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot neutral hold | Starting valueDisabled | What it controls and whyPermits centering hold during a supported AP state, separate from following a moving target. |
| Output force limit | Starting value0.55 | What it controls and whyCaps directed-force output. Native spring effects and device limits remain separate. |
All 44 starting settings and their rationale
The settings define the profile’s effect balance. Device output limits affect physical hand force.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring strength | Starting value0.8 | What it controls and whyThe powered-control spring approximates artificial pitch feel; the actual Mach/altitude Q-feel schedule and roll-ratio mechanism are not reproduced by one IAS reference. The baseline spring is 0.8. Its low-speed blend reaches baseline strength at 90 KIAS. |
| Spring deadband | Starting value0.035 | What it controls and whySets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Profile force gain | Starting value0.25 | What it controls and whyThe aerodynamic-load gain is 0.25 with an indicated-speed reference of 300 KIAS. The hydraulic-load factor of 0.35 scales that modeled term; it is a selected artificial-feel approximation. |
| Master force gain | Starting value0.85 | What it controls and whyScales overall profile strength while preserving effect balance, subject to device and output limits. |
| QBlend Enabled | Starting valueEnabled | What it controls and whyAllows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| QSpring Minimum Factor | Starting value0.55 | What it controls and whySets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| QSpring Start Knots | Starting value20 kt | What it controls and whySets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring response reference speed | Starting value90 kt | What it controls and whySets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Force tuning speed/reference | Starting value300.0 kt | What it controls and whySets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening gain | Starting value0 | What it controls and whyThe high-speed spring-stiffening gain is 0. No additional speed-driven stiffening is added; this does not disable independent aerodynamic loading. |
| Airspeed spring stiffening limit | Starting value5 | What it controls and whyLimits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | Starting value0.65 | What it controls and whyRoll and pitch aerodynamic scales are 0.65 and 0.65, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | Starting value0.65 | What it controls and whyScales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Output force limit | Starting value0.55 | What it controls and whyCaps directed-force output. Native spring effects and device limits remain separate. |
| Trim feel | Starting valueEnabled | What it controls and whyRetained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| Trim relief | Starting valueEnabled | What it controls and whyAllows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| Elevator Authority | Starting value0.3 | What it controls and whyCustom pitch trim is documented, but the profile's permitted centre response remains a simplified feel representation rather than a verified generic trim interface. Pitch authority 0.3 relieves permitted loading; hydraulic centre movement is off. Roll authority is 0.09. |
| Aileron Authority | Starting value0.09 | What it controls and whyScales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| Force Trim Enabled | Starting valueDisabled | What it controls and whyEnables local force trim, separate from aircraft-owned trim and add-on integration qualification. |
| GLoad Enabled | Starting valueEnabled | What it controls and whyAllows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| Rate Damping Enabled | Starting valueEnabled | What it controls and whyEnables rate damping with the configured coefficients and control law. |
| Autopilot follow | Starting valueDisabled | What it controls and whyAutopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot follow authority | Starting value0.1 | What it controls and whySets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot neutral hold | Starting valueDisabled | What it controls and whyPermits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot neutral hold strength | Starting value0.6 | What it controls and whySets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Enabled | Starting valueEnabled | What it controls and whyEnables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Gain | Starting value0.3 | What it controls and whySets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Gain | Starting value0 | What it controls and whySets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Gain | Starting value0 | What it controls and whySets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Maximum flap index | Starting value1 | What it controls and whySets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Minimum flap index | Starting value1 | What it controls and whySets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Gain | Starting value0.1 | What it controls and whySets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Shaker Enabled | Starting valueEnabled | What it controls and whyPermits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Stick shaker amplitude | Starting value0.9 | What it controls and whySets triggered shaker strength; inactive while the shaker feature is disabled. |
| Enabled | Starting valueEnabled | What it controls and whyEnables ground effects; each still needs its own strength and contact or motion telemetry. |
| Gain | Starting value0.4 | What it controls and whySets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Gain | Starting value0.32 | What it controls and whySets gear-bump texture during ground motion, separate from touchdown impact. |
| Gain | Starting value0.9 | What it controls and whySets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Gain | Starting value0.5 | What it controls and whySets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Enabled | Starting valueEnabled | What it controls and whyEnables engine cues with nonzero settings and valid running-engine telemetry. |
| Gain | Starting value0.06 | What it controls and whySets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Enabled | Starting valueEnabled | What it controls and whyEnables accessory cues with configured strengths and observed accessory movement. |
| Gain | Starting value0 | What it controls and whySets texture from observed flap movement; a command without movement does not establish the cue. |
| Gain | Starting value0.12 | What it controls and whySets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
Limits and open questions
- The Q-feel description supports qualitative artificial feel, but supplies no exact schedule or pitch-to-roll force ratio for calibration.
Physical validation
No physical force validation is recorded in this public catalogue for this revision. Documentary review and software checks do not establish how a particular device feels.
Discuss this aircraft (0)
Questions, observations and useful sources from the community.
No published discussions yet. Bring a question or share a useful source.
Open aircraft discussions →Content expanded · What’s new
Something missing or a source that needs attention?
Suggest a correction ↗