Start here
A few places to begin, from the aircraft’s story to the people who fly it.
Meet the aircraft
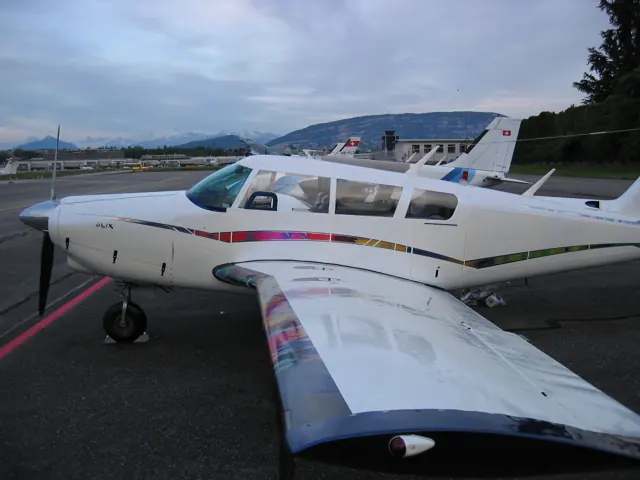
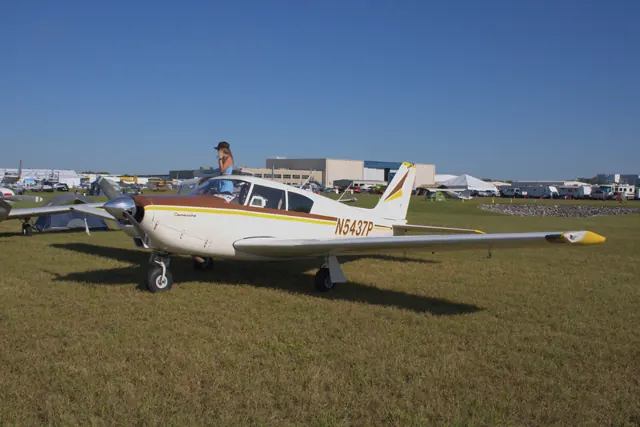
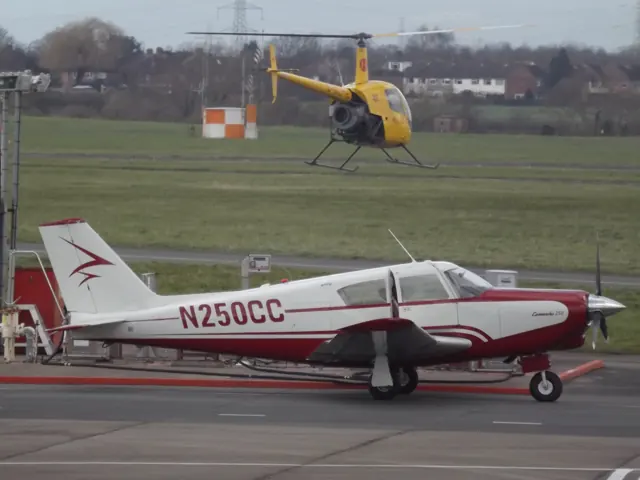
Piper's Comanche first flew in 1956 with an all-metal low-wing airframe, enclosed cabin and retractable tricycle gear. Later versions changed engine power and seating, alongside the separate Twin Comanche line.
Aircraft background
Wikipedia contributors · Read more ↗A restored 250 on a short grass runway
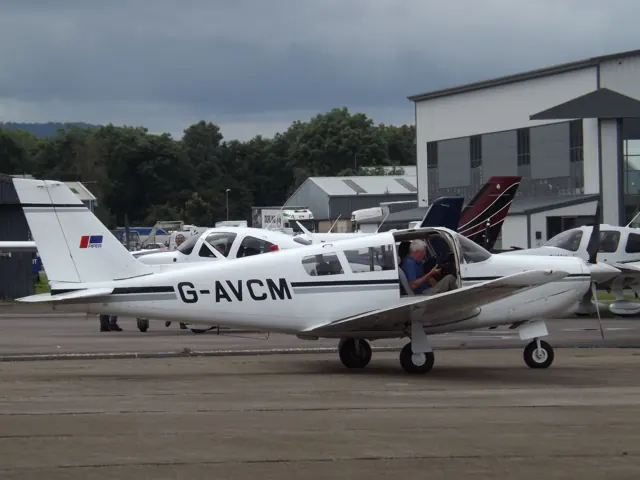
Unwin flew Mark Bonsall's refurbished 1963 Comanche 250 from Netherthorpe with instructor Nick Riddin. This particular aircraft had fuel injection and a three-blade propeller, so it was not an untouched factory example. With two aboard and partial fuel, it accelerated briskly from the grass strip.
30 March 2017. Modified PA-24-250 N61970, Netherthorpe, United Kingdom.
Pilot · Read more ↗An aircraft that retains its mechanical history
A2A's Accu-Sim 2 Comanche uses its external Merlin flight-physics system and a per-cylinder engine model. The manual describes fuel priming, fuel contamination and ground behaviour that responds to tyre loading. Persistent aircraft condition connects one simulator session with the next, while the maintenance and inspection interfaces make that condition visible.
Piper Comanche · A2A · MSFS 2024 · MSFS 2020
A2A Simulations · Read more ↗Into the cockpit
 YouTube
A2A Simulations
A2A Accu-Sim Comanche 250 Autopilot Guide | S-TEC (MSFS2020/24) & GPSS Explained (MSFS 2024)
A guide to the S-TEC autopilot and the native 2024 edition's GPSS feature.
A2A Comanche; MSFS 2020/2024; GPSS specific to native 2024
Watch on YouTube ↗Preview images are served by AirframeDB. Videos open on YouTube only when you choose to watch.
Meet Piper Comanche
Piper's Comanche first flew in 1956 with an all-metal low-wing airframe, enclosed cabin and retractable tricycle gear. Later versions changed engine power and seating, alongside the separate Twin Comanche line.
Production ended after the 1972 flood at Piper's Lock Haven plant. A2A models a particular Comanche with persistent engine and airframe condition; its manual describes the loading, maintenance and mechanical systems included in the simulation.
Piper Comanche
Piper → · Explore the family →
Piper Comanche
Wikipedia contributors · Piper PA-24 Comanche ↗A2A · MSFS 2024 · MSFS 2020 →Aircraft type designators
Use the code for the model you are flying. The linked authority lists the applicable aircraft.
History & design
Development milestones
First flight: May 24, 1956
Wikipedia contributors · Piper PA-24 Comanche ↗Piper PA-24 Comanche · family/variant named by the source · Wikipedia revision 1371634258
Systems & details
A moving tailplane and hand-operated flaps
The Comanche 250’s pitch control uses a stabilator: the horizontal tail moves as a unit instead of carrying a separate hinged elevator. Its anti-servo tab also provides longitudinal trim. A2A’s aircraft description pairs that arrangement with manually operated flaps and conventional yoke-and-pedal controls. This combination gives the cockpit several distinct mechanical controls, even before the separate engine and propeller levers are considered.
Landing gear connected by cables and a gear train
An electric motor and reduction mechanism beneath the floor move the three landing-gear units through push-pull cables. The nosewheel steering disconnects as the gear retracts, reducing the steering mechanism’s contribution to airborne rudder-pedal loads. The manual also describes a ground anti-retraction switch and separate indications for gear position. The selector operates the documented electrical and mechanical landing-gear system.
Documented detail
The list supplies trim-required lights and AP controls, and identifies the elevator trim handle with a standard SimVar requested in percent.
Pilot accounts
A restored 250 on a short grass runway
Unwin flew Mark Bonsall's refurbished 1963 Comanche 250 from Netherthorpe with instructor Nick Riddin. This particular aircraft had fuel injection and a three-blade propeller, so it was not an untouched factory example. With two aboard and partial fuel, it accelerated briskly from the grass strip. Unwin liked the harmonisation of the primary controls and their low initial resistance, although he found the older instrument and engine-control layout less intuitive than a modern cockpit. In airwork, his stalls gave clear warning and little inclination to drop a wing.
The landing and photo flights exposed different demands. He could feel the aircraft entering ground effect and thought excess approach speed would produce a long float; careful speed control rewarded him with successive satisfactory landings. Flying close formation for the photographer required more work, partly because the view from his chosen seat was restrictive. His overall appreciation was for a capable touring aircraft, with handling observations tied to the loading and modifications of the example he actually flew.
30 March 2017. Modified PA-24-250 N61970, Netherthorpe, United Kingdom.
Read the full account · Pilot ↗Why an experienced owner kept his 1958 Comanche
Wall's attachment to the Comanche began with a flying-club comparison in 1958. Interviewed by Bill Cox, he recalled flying a loaded Comanche 250 and a contemporary Bonanza between Burbank and Phoenix. He considered the Comanche the stronger performer in that particular comparison, while acknowledging the appeal of the Beechcraft's handling. Decades later, after a professional flying career, that experience helped draw him back to a 1958 Comanche of his own.
By the 2005 article, Wall had accumulated more than a thousand hours in the type and restored his aircraft extensively. He distinguished brochure claims from his experience: the advertised climb figure seemed optimistic to him, while maximum cruise was closer to what he observed. His usual choice was an economical high-altitude cruise rather than maximum speed. As an owner and mechanic, he also valued access for maintenance and familiarity with the systems he had rebuilt. These are the preferences and reported results of one experienced owner, rather than a controlled comparison of all Comanches and Bonanzas.
1 March 2005. Owner account of a 1958 Comanche 250, including a recalled 1958 comparison.
Read the full account · Plane & Pilot ↗An unannounced Comanche with considerably more power
Looking back on his test-flying years, Kershner remembered the Comanche 400 as one of the aircraft that stood out. He identified the two final test aircraft and explained Pug Piper's interest in obtaining high-altitude performance without turbocharging. The extra power gave him an impression reminiscent of a fighter, but he also recalled substantial fuel consumption and troublesome hot starts during the flight-test period. His account concerns the eight-cylinder 400, a different proposition from the familiar 180 and 250.
One flight supplied the story's human detail. Over Lock Haven, he overtook a conventional Comanche and made further passes that prompted its pilot to ask what version he was flying. Kershner gave an evasive answer over the radio, then returned to a reprimand for drawing attention to an aircraft Piper had not yet announced. He also remembered watching the fuel indication move towards empty.
May 1997. Retrospective by Piper test pilot William K. Kershner; PA-24-400 subsection.
Read the full account · AOPA Pilot ↗The owner whose Comanche became the simulation
In the manual's developer notes, Gentile explains why A2A chose his own Comanche 250, N6229P, for its new Accu-Sim system. He had owned and operated the aeroplane for more than a decade. That familiarity gave the team continuing access to an aircraft they could examine and fly while investigating questions raised during development. His account describes the connection between an owner's long experience and the choice of a simulation subject.
Gentile's affection is equally explicit. He values the Comanche's combination of speed, load-carrying ability, cabin room and manageable handling, and says the aircraft has become part of the family. The appeal began with its appearance and deepened over years of operation. This is an enthusiastic owner's introduction, written by the developer selling the simulation, rather than an independent comparison flight.
Scott Gentile, A2A Comanche 250 manual (2023) · PDF p.7 / printed p.5 · owner of N6229P and A2A president.
Read the full account · A2A Simulations ↗In your simulator
Systems, equipment and documentation for each developer’s aircraft.
MSFS 2024 · MSFS 2020Piper Comanche · A2A
A2A · Released
Piper Comanche · A2A
A2A · Released
Aircraft specifications
Published figures for the named real-aircraft variant. Simulator equipment and performance can differ.
| Specification | Published value |
|---|---|
| Length | 25 ft 0 in (7.62 m) |
| Wingspan | 36 ft 0 in (10.97 m) |
| Height | 7 ft 6 in (2.29 m) |
| Wing area | 178 sq ft (16.5 m² ) |
| Empty weight | 1,773 lb (804 kg) |
| Max takeoff weight | 3,200 lb (1,451 kg) |
| Powerplant | 1 × Lycoming IO-540 air-cooled six-cylinder horizontally-opposed engine, 260 hp (190 kW) |
| Propellers | 2-bladed Hartzell HC82XK1D metal constant-speed propeller , 6 ft 5 in (1.96 m) diameter |
| Maximum speed | 195 mph (314 km/h, 169 kn) at sea level |
| Cruise speed | 185 mph (298 km/h, 161 kn) at 6,300 ft (1,900 m) (max. cruise, 75% power) |
| Range | 1,225 mi (1,971 km, 1,064 nmi) at 10,500 ft (3,200 m) (auxiliary fuel tanks, 65% power) |
| Service ceiling | 19,500 ft (5,900 m) |
| Rate of climb | 1,320 ft/min (6.7 m/s) |
Manuals & resources
Find your next read
Choose a topic for a short introduction and a link to the original source. Simulator references identify the developer and edition they cover.
Simulator documentation
An aircraft that retains its mechanical historyPiper Comanche · A2A · A2A · MSFS 2024 · MSFS 2020
A2A's Accu-Sim 2 Comanche uses its external Merlin flight-physics system and a per-cylinder engine model. The manual describes fuel priming, fuel contamination and ground behaviour that responds to tyre loading. Persistent aircraft condition connects one simulator session with the next, while the maintenance and inspection interfaces make that condition visible. The full manual is the starting point for understanding the aircraft; the separate variable list serves cockpit builders.
Accu-Sim 2 Comanche for MSFS · PDF p.8; features and systems
A2A Simulations · Read the source ↗Condition, inspections and configurable equipmentPiper Comanche · A2A · A2A · MSFS 2024 · MSFS 2020
The maintenance interface records engine and airframe hours and provides an inspection diagram showing the condition of individual systems. Its New, Used and Auction starting conditions give the same aircraft different mechanical histories; the Auction option can produce a wide range of condition. The maintenance page also provides an overhaul function. The manual describes selectable airframe modifications, soundproofing and a choice of McCauley or MT three-bladed propeller. These are configuration options within A2A's model. These features are specific to A2A's Comanche.
Accu-Sim Comanche 250 for MSFS · PDF pp.22,50–51 / printed pp.20,48–49
A2A Simulations · Read the source ↗Loading the aircraft belongs to Accu-SimPiper Comanche · A2A · A2A · MSFS 2024 · MSFS 2020
The Comanche's tablet handles fuel, passengers and baggage through Accu-Sim's own simulation. A2A states that the default MSFS weight-and-balance menu is not supported for this aircraft because the model uses external code. The tablet shows a live centre-of-gravity diagram as the load changes, provides fuel presets and can update the JPI engine monitor's fuel state. This is a consequential difference from a default simulator aircraft, even before considering how either one flies.
Accu-Sim Comanche 250 for MSFS · PDF p.50 / printed p.48 · Fuel and payload
A2A Simulations · Read the source ↗Pilot account
A restored 250 on a short grass runway30 March 2017. Modified PA-24-250 N61970, Netherthorpe, United Kingdom.
Unwin flew Mark Bonsall's refurbished 1963 Comanche 250 from Netherthorpe with instructor Nick Riddin. This particular aircraft had fuel injection and a three-blade propeller, so it was not an untouched factory example. With two aboard and partial fuel, it accelerated briskly from the grass strip. Unwin liked the harmonisation of the primary controls and their low initial resistance, although he found the older instrument and engine-control layout less intuitive than a modern cockpit.
Dave Unwin
Pilot · Read the source ↗Why an experienced owner kept his 1958 Comanche1 March 2005. Owner account of a 1958 Comanche 250, including a recalled 1958 comparison.
Wall's attachment to the Comanche began with a flying-club comparison in 1958. Interviewed by Bill Cox, he recalled flying a loaded Comanche 250 and a contemporary Bonanza between Burbank and Phoenix. He considered the Comanche the stronger performer in that particular comparison, while acknowledging the appeal of the Beechcraft's handling. Decades later, after a professional flying career, that experience helped draw him back to a 1958 Comanche of his own.
Robert Wall, interviewed by Bill Cox
Plane & Pilot · Read the source ↗Read the original documentation from the people who created it. Manuals open on their publisher’s website.
Manual
Comanche Pilot ManualA2A Simulations Comanche variables listA2A Simulations Microsoft Flight Simulator aircraft manualsMicrosoft / aircraft developersAircraft background
Piper PA-24 ComancheWikipedia contributors · Research background · Wikipedia revision 1371634258 · retrieved 2026-09-12Product
Accu-Sim Comanche · native MSFS 2024A2A Simulations · Official developer / designated store catalogue · checked 2026-09-12 Accu-Sim Comanche · MSFS 2020A2A Simulations · Official developer / designated store catalogue · checked 2026-09-12Type designator
ICAO Doc 8643 — aircraft type designatorsInternational Civil Aviation Organization · Public search data retrieved 2026-09-14; authority update 2026-09-03Built-in force-feedback profiles
Read the documentary basis, editable starting settings and remaining questions for the aircraft you fly. Each explanation refers to the exact profile revision shown.
Catalogue programme-20261022-v1 · 2 profile choices
A2A Comanche 250
A2A · Free and Pro · Revision 5 · Inherited starting point
MSFS 2020 · MSFS 2024
A2A Comanche 250: The stabilator/anti-servo arrangement motivates reversible yoke loading.
Piper Comanche
Free and Pro · Revision 2 · Partial review
MSFS 2024 · MSFS 2020
Piper Comanche: The stabilator/anti-servo arrangement motivates reversible yoke loading.
Piper Comanche
Piper Comanche: The stabilator/anti-servo arrangement motivates reversible yoke loading.
Aircraft and simulator scope
- Piper Comanche · MSFS 2024 · family starting point
- Piper Comanche · MSFS 2020 · family starting point
Piper Comanche · Family sources identify only the variants and product versions described above.
The simulator model and controls
Piper's Comanche first flew in 1956 with an all-metal low-wing airframe, enclosed cabin and retractable tricycle gear. Later versions changed engine power and seating, alongside the separate Twin Comanche line.
This starting point selects Piper Comanche. Its aircraft-level settings do not select a particular developer’s custom systems.
How this profile feels
The stabilator/anti-servo arrangement motivates reversible yoke loading. Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.
The anti-servo tab supplies pitch relief; ALT-mode trim lamps request manual action. Valid trim provides the configured pressure relief. Autopilot following is enabled for supported control references.
Controls and trim
The Comanche’s manually controlled stabilator uses an anti-servo tab for longitudinal trim. A2A’s S-TEC30 altitude hold has an elevator servo and lamps requesting pilot trim, without automatic pitch trim. Native 2024 GPSS supplies lateral steering as a separate addition.
About the values
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
What the documentation establishes
A2A manuals identify PA-24-250 Comanche, not every PA-24 variant.
A2A identifies PA-24-250 and S-TEC30 equipment.
Documentary review and sources
These decisions describe the documentary basis and remaining gaps for this revision. Aircraft documentation and a starting setting describe different kinds of evidence.
Aircraft and variant
ReviewedThis starting point selects Piper Comanche. Its aircraft-level settings do not select a particular developer’s custom systems.
Flight controls
Not yet reviewedThe Comanche’s manually controlled stabilator uses an anti-servo tab for longitudinal trim. A2A’s S-TEC30 altitude hold has an elevator servo and lamps requesting pilot trim, without automatic pitch trim. Native 2024 GPSS supplies lateral steering as a separate addition.
Trim
Not yet reviewedThe anti-servo tab supplies pitch relief; ALT-mode trim lamps request manual action. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.
Autopilot and stability
Not yet reviewedFollowing is on at 0.1 authority when a supported, valid autopilot control reference is available.
Equipment
ReviewedGear, flap and ground cues follow the selected settings and available simulator-reported states.
Speeds and limits
Not yet reviewedThe indicated-speed references set the profile response scale; they are separate from aircraft operating limits.
Simulator integration
Not yet reviewedThe profile targets msfs2024, msfs2020. Add-on-specific controls use only the supported references configured by this profile.
Force-feedback settings
Not yet reviewedThe settings define the profile’s effect balance. Device output limits affect physical hand force.
Starting settings and their rationale
These configured values are starting estimates. The explanations describe what each setting controls; physical validation appears separately below.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring strength | Starting value0.74 | What it controls and whyThe stabilator/anti-servo arrangement motivates reversible yoke loading. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 75 KIAS. |
| Master force gain | Starting value0.85 | What it controls and whyScales overall profile strength while preserving effect balance, subject to device and output limits. |
| Profile force gain | Starting value0.8 | What it controls and whyThe aerodynamic-load gain is 0.8 with an indicated-speed reference of 150 KIAS. This supplies speed-dependent loading alongside the spring. |
| Force tuning speed/reference | Starting value150.0 kt | What it controls and whySets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Spring response reference speed | Starting value75.0 kt | What it controls and whySets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Aileron force scale | Starting value0.72 | What it controls and whyRoll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | Starting value1.0 | What it controls and whyScales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Trim feel | Starting valueEnabled | What it controls and whyRetained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| Trim relief | Starting valueEnabled | What it controls and whyAllows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| Autopilot follow | Starting valueEnabled | What it controls and whyFollowing is on at 0.1 authority when a supported, valid autopilot control reference is available. |
| Autopilot neutral hold | Starting valueDisabled | What it controls and whyPermits centering hold during a supported AP state, separate from following a moving target. |
| Output force limit | Starting value0.55 | What it controls and whyCaps directed-force output. Native spring effects and device limits remain separate. |
All 44 starting settings and their rationale
The settings define the profile’s effect balance. Device output limits affect physical hand force.
| Setting | Starting value | What it controls and why |
|---|---|---|
| Spring strength | Starting value0.74 | What it controls and whyThe stabilator/anti-servo arrangement motivates reversible yoke loading. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 75 KIAS. |
| Spring deadband | Starting value0.045 | What it controls and whySets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Profile force gain | Starting value0.8 | What it controls and whyThe aerodynamic-load gain is 0.8 with an indicated-speed reference of 150 KIAS. This supplies speed-dependent loading alongside the spring. |
| Master force gain | Starting value0.85 | What it controls and whyScales overall profile strength while preserving effect balance, subject to device and output limits. |
| QBlend Enabled | Starting valueEnabled | What it controls and whyAllows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| QSpring Minimum Factor | Starting value0.5 | What it controls and whySets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| QSpring Start Knots | Starting value20 kt | What it controls and whySets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring response reference speed | Starting value75.0 kt | What it controls and whySets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Force tuning speed/reference | Starting value150.0 kt | What it controls and whySets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening gain | Starting value0.15 | What it controls and whyThe high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 75 KIAS, with the squared-speed ratio capped at 5. |
| Airspeed spring stiffening limit | Starting value5 | What it controls and whyLimits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | Starting value0.72 | What it controls and whyRoll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | Starting value1.0 | What it controls and whyScales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Output force limit | Starting value0.55 | What it controls and whyCaps directed-force output. Native spring effects and device limits remain separate. |
| Trim feel | Starting valueEnabled | What it controls and whyRetained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| Trim relief | Starting valueEnabled | What it controls and whyAllows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| Elevator Authority | Starting value0.3 | What it controls and whyThe anti-servo tab supplies pitch relief; ALT-mode trim lamps request manual action. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0. |
| Aileron Authority | Starting value0 | What it controls and whyScales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| Force Trim Enabled | Starting valueDisabled | What it controls and whyEnables local force trim, separate from aircraft-owned trim and add-on integration qualification. |
| GLoad Enabled | Starting valueEnabled | What it controls and whyAllows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| Rate Damping Enabled | Starting valueEnabled | What it controls and whyEnables rate damping with the configured coefficients and control law. |
| Autopilot follow | Starting valueEnabled | What it controls and whyFollowing is on at 0.1 authority when a supported, valid autopilot control reference is available. |
| Autopilot follow authority | Starting value0.1 | What it controls and whySets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot neutral hold | Starting valueDisabled | What it controls and whyPermits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot neutral hold strength | Starting value0.6 | What it controls and whySets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Enabled | Starting valueEnabled | What it controls and whyEnables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Gain | Starting value0.35 | What it controls and whySets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Gain | Starting value0 | What it controls and whySets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Gain | Starting value0.14 | What it controls and whySets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Maximum flap index | Starting value3 | What it controls and whySets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Minimum flap index | Starting value2 | What it controls and whySets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Gain | Starting value0.1 | What it controls and whySets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Shaker Enabled | Starting valueDisabled | What it controls and whyPermits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Stick shaker amplitude | Starting value0.5 | What it controls and whySets triggered shaker strength; inactive while the shaker feature is disabled. |
| Enabled | Starting valueEnabled | What it controls and whyEnables ground effects; each still needs its own strength and contact or motion telemetry. |
| Gain | Starting value0.4 | What it controls and whySets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Gain | Starting value0.25 | What it controls and whySets gear-bump texture during ground motion, separate from touchdown impact. |
| Gain | Starting value0.65 | What it controls and whySets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Gain | Starting value0 | What it controls and whySets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Enabled | Starting valueEnabled | What it controls and whyEnables engine cues with nonzero settings and valid running-engine telemetry. |
| Gain | Starting value0.12 | What it controls and whySets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Enabled | Starting valueEnabled | What it controls and whyEnables accessory cues with configured strengths and observed accessory movement. |
| Gain | Starting value0.12 | What it controls and whySets texture from observed flap movement; a command without movement does not establish the cue. |
| Gain | Starting value0.12 | What it controls and whySets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
Limits and open questions
- Stabilator/manual loading is a starting estimate, not calibrated gearing.
- A2A trim behavior does not provide a measured relief ratio.
- A2A lists S-TEC30 and custom AP variables; generic follow is not an implemented mapping.
- Limits are IAS in mph with stabilator-tip differences; none is copied as the knot loading anchor.
- Named A2A historical acceptance is not broadened to this generic choice; custom signals need a contract.
- Stabilator tips/loading/Accu-Sim trim affect feel; generic strengths remain estimates.
Physical validation
No physical force validation is recorded in this public catalogue for this revision. Documentary review and software checks do not establish how a particular device feels.
Documented interfaces
Source-documented identifiers. Documentation does not prove that every add-on populates a value correctly.
L:ApTrimUpLight
Trim-up-required lamp.
- Units
- bool
- Access
- not specified by variable list
Public list revision unlabelled
A2A Simulations · PDF page 1 ↗L:ApTrimDnLight
Trim-down-required lamp.
- Units
- bool
- Access
- not specified by variable list
Public list revision unlabelled
A2A Simulations · PDF page 1 ↗L:ApMaster
Autopilot master switch; not proof servos active.
- Units
- not specified
- Access
- not specified by variable list
Public list revision unlabelled
A2A Simulations · PDF page 3 ↗ELEVATOR TRIM PCT
Elevator trim handle binding.
- Units
- percent (A2A request)
- Access
- not specified by list
Public list revision unlabelled
A2A Simulations · PDF page 8 ↗Discuss this aircraft (0)
Questions, observations and useful sources from the community.
No published discussions yet. Bring a question or share a useful source.
Open aircraft discussions →Content expanded · What’s new
Something missing or a source that needs attention?
Suggest a correction ↗